
12V Linear Actuators Fit Checker and Sizing Guide
Compare 12V linear actuators by estimated current and supply margin using load, stroke, speed, and duty inputs. This is a screening estimate; verify the selected model’s force limits. If you need a 12V linear actuator with a limit switch, verify switch presence and reverse wiring in the exact model’s datasheet; this tool does not validate switch circuitry. Read the model-specific limit-switch FAQ.
Published by Custom Linear ActuatorJump to tool or section
12V fit checker
Defaults are ready to run. Estimate current and supply margin, then verify the exact model before RFQ.
Decision summary
Use these conclusions to decide whether a candidate 12V electric actuator is worth validating, what evidence is missing, and when to request supplier review.
View 4 additional conclusions
Applicability scope
Use this matrix to determine whether this page is directly applicable, conditionally usable, or not sufficient for release decisions.
12V Push-Pull Actuator: Bidirectional Mechanics & Polarity Control
Screen the electrical demand first, then qualify mechanical loads and direction control for the selected model. Powered extension and retraction do not establish equal load ratings.
Evidence checked 2026-11-03. Thomson documents equal directional ratings for many models, alongside model-specific compression limits. This guide infers the checks below from those distinctions; it does not supply a rated 12V actuator curve. Thomson catalogue, p. 244.
12V Push vs. Pull Sizing & Boundary Matrix
Swipe horizontally to read all columns.
| Decision | Push / compression check | Pull / tension check | Evidence and next action |
|---|---|---|---|
| Directional force and stroke | Confirm dynamic and static compression ratings; check column strength at the required extension. | Confirm dynamic and static tension ratings and joint/retention capacity. | S_PUSHPULL_1 / S_PUSHPULL_COLUMN: request the exact model curve; no universal stroke cutoff. |
| Electrical screening | Enter the resisting load and loaded speed for extension. | Repeat with the resisting load and loaded speed for retraction. | This tool estimates F × v / (V × efficiency). Assisting loads, stall and reversal peaks remain unknown. |
| Static holding and side loads | Check unpowered holding and compression stability; use permitted mounting. | Check unpowered holding and joint alignment; pure tension does not qualify side loading. | S_PUSHPULL_1: use model limits. Screw type alone is insufficient; add a rated brake or external guide if required. |
| Direction control and end limits | Verify the extension stop and return path from its schematic. | Verify the retraction stop and return path from its schematic. | S_LIMIT_SWITCH_1 / S_PUSHPULL_DRIVER: topology is model-specific; do not copy generic diode values. |
| Reversal and system cost | Capture loaded stop and direction-change current/voltage. | Repeat under the worst assisting or resisting condition. | S_PUSHPULL_REVERSAL: validate sequencing and regeneration; include controls, protection and test costs in the RFQ. |
Tradeoffs: a simple reversing switch can suit infrequent manual travel if rated for the motor load. Frequent reversals may justify a current-controlled driver and added validation cost. For an assisting or overhauling load, request braking/regeneration and holding review; this resisting-load power model does not cover that case. An external guide or different mechanism may be needed where side loads cannot be removed.
12V Screw Actuator: Drive Selection and Efficiency
Compare screw mechanisms, run the same load-speed case, then verify duty and power-off holding on the complete actuator.
Evidence checked 2026-11-03. A 12V screw actuator is covered by this single sizing guide. Screw efficiency affects current, but the tool needs total motor, gearbox and screw efficiency. The examples below compare assumptions; they are not measured product ratings or proof of suitability.
Screw drive decision matrix
Known mechanism differences and conditional arithmetic are separated from missing candidate data. Roller-screw product performance is unverified here.
Swipe horizontally to read all columns.
| Decision | Acme | Ball screw | Roller screw | Next step / evidence |
|---|---|---|---|---|
| Contact type and purchase cost | Sliding screw/nut contact; often the lower-cost option. | Rolling balls and return path; include lubrication and holding hardware in the quote. | Threaded rollers; obtain model-specific pricing and availability. | Compare complete installed systems, including brake, controller, maintenance and validation costs. Sources: S_SCREW_THOMSON, S_SCREW_THK. |
| Screw efficiency versus whole-actuator efficiency | 30% screw efficiency in this hypothetical example. | 90% screw efficiency in the same hypothetical example. | Unknown for the candidate; request efficiency and current curves. | With assumed 85% gearbox and 70% motor efficiency, enter 17.85% or 53.55% TOTAL efficiency. Screw-only efficiency is not the calculator input. Source: S_SCREW_THOMSON; component factors are assumptions. |
| 12V running current at 200 lbf and 0.45 in/s | 4.75 A calculated at 17.85% total efficiency. | 1.58 A calculated at 53.55% total efficiency. | Unknown without an operating-point efficiency or current curve. | These are conditional examples, not measured product ratings. Startup uses an assumed 1.7× multiplier; verify startup, stall and reversal separately. |
| Power-off holding | May self-lock, depending on lead, friction, lubrication and wear; thread type alone does not qualify holding. | Can backdrive; do not assume unpowered holding. | Holding behavior is unverified for the candidate. | Specify a rated power-off holding brake or independent restraint where load movement is hazardous. Verify the assembled axis. Sources: S_SCREW_THOMSON, S_SCREW_THK. |
| Heat and duty rating | 46.8 W total actuator loss in the hypothetical example; heat distribution is unknown. | 8.8 W total actuator loss in the hypothetical example; continuous duty is unverified. | Continuous duty is unverified; screw type does not establish a thermal rating. | Obtain permitted duty, maximum on-time and ambient/load limits for the complete actuator. Lower loss alone does not establish duty. Source: S_SCREW_DUTY. |
| Compression, speed and positioning | Check unsupported length, support bearings, wear and backlash on the exact model. | Check buckling, critical speed, preload, backlash and lubrication on the exact model. | Load density, stiffness, backlash and shock capability require supplier data; no universal multiplier is established here. | Use rated load and life curves at the same lead, stroke and support arrangement. Ask for loaded repeatability and shock limits. Sources: S_SCREW_THK, S_SCREW_ASME_B1_5. |
Evidence register: Thomson Linear: Lead Screws — technology comparisonTHK: Ball Screw — features and thrust/torque relationshipsAmerican Society of Mechanical Engineers: ASME B1.5-1997 (R2024): Acme Screw ThreadsThomson Linear: Linear Actuators — duty cycle and on-time glossary
12V Telescopic Linear Actuators: Packaging, Current and Structural Checks
Screen electrical demand above, then verify closed dimensions, stage motion and allowable loads on the exact candidate.
Evidence checked 2026-11-03. Nested stages can solve a tight installation envelope, but a 12V label and stage count do not establish closed length, lifting capacity or current. The checker estimates electrical demand only. Geometry, buckling, holding and environmental suitability remain unverified.
Telescopic actuator architecture decision matrix
Swipe horizontally to read all columns.
| Feature | Telescopic multi-stage | Standard single-stage | Track / slider | Next step / evidence |
|---|---|---|---|---|
| Closed envelope and stroke | Nested stages can reduce closed length; stage count alone does not determine the ratio. | Check closed pin-to-pin length, motor offset and end fittings on the drawing. | Fixed rail footprint includes carriage and end supports; verify its full envelope. | Compare candidate drawings at the same stroke. Do not freeze chassis cutouts from a generic ratio. Sources: S_TELESCOPIC_KINEMATICS, S_TELESCOPIC_SYNCHRONOUS. |
| Compression and structural support | Stepped sections, overlap, joint compliance and mounting affect stability. | Rod extension and end conditions affect compression limits; constant capacity is not assured. | Rail support does not remove screw, bearing, fastener or base load limits. | Request allowable load versus extension and mounting data; have the complete structure checked. A uniform Euler model is educational only. Source: S_TELESCOPIC_BUCKLING. |
| Side load and bending moments | Axial-only rods and moment-rated lifting columns are different architectures. | Do not assume a rod actuator accepts side loads without a published rating. | Use published carriage force and moment limits, including mounting orientation. | Use external guides for an axial-only rod or select a rated guided column. Spherical ends accommodate alignment but do not support lateral loads. Sources: S_TELESCOPIC_THOMSON, S_TELESCOPIC_EWELLIX_LINAK. |
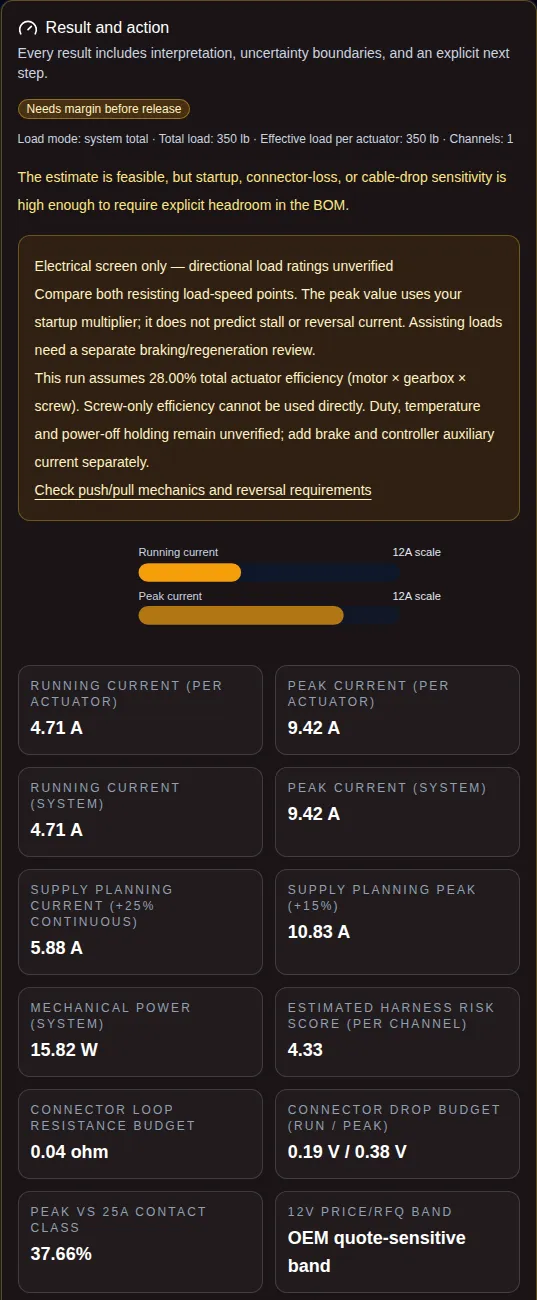
| 12V current and supply sizing | Whole-actuator efficiency and startup waveform are unknown until specified or measured. | Screw-only efficiency cannot establish motor input current. | Include motor, transmission, control and auxiliary losses. | The tool sample assumes 28% total efficiency and 2x startup: 4.71 A run and 9.42 A peak. These are not a supply recommendation; validate duration, voltage drop and current limiting. Source: S_TELESCOPIC_ELECTRICAL. |
| Stage motion and controls | Mechanically coordinated stages differ from sequential mechanisms; speed and current remain load-dependent. | Motor speed, load and control determine travel speed. | Validate speed under load, end limits and control response. | Ask for motion and current traces over the full stroke in both directions. NEFF S-TEG is a mechanical example, not proof of a complete 12V actuator. Source: S_TELESCOPIC_SYNCHRONOUS. |
| Environment and installed cost | Multiple moving interfaces need model-specific ingress and temperature qualification. | One moving rod seal does not establish any IP rating. | Check exposed rails, covers and lubrication requirements. | Budget guides, controller, harness, maintenance and loaded validation. Request wet/cold testing for outdoor use; do not add drain holes without manufacturer approval. Source: S_TELESCOPIC_EWELLIX_LINAK. |
Evidence register: Thomson Linear: What is side loading and how does it affect my actuator?LINAK: LC3: 2-stage and 3-stage lifting columnMIT OpenCourseWare · David M. Parks: 2.002 lecture: Euler-Bernoulli Beams, Bending, Buckling and Vibrationmaxon Support: Motor data and simulationLINAK: LC3 data sheet: voltage, bending moment and operating conditionsNEFF Gewindetriebe: S-TEG telescopic screw drives product handout
Method and assumptions
The model is transparent by design. It turns force-speed demand into current, then adds margin for startup and duty stress.
Published and maintained by Custom Linear Actuator. Source-based engineering screening, originally created 2026-04-07; reviewed 2026-11-03. Request model-specific evidence from the supplier before approving a design.
Reproducible tool-run evidence
These checkpoints combine calculator outputs with explicit arithmetic checks tied to cited source limits, so reviewers can reproduce both current and boundary calculations.
Review all 8 reproducible tool runs
Swipe horizontally to read all columns.
| Case | Profile | Calculated output | Decision signal | Evidence |
|---|---|---|---|---|
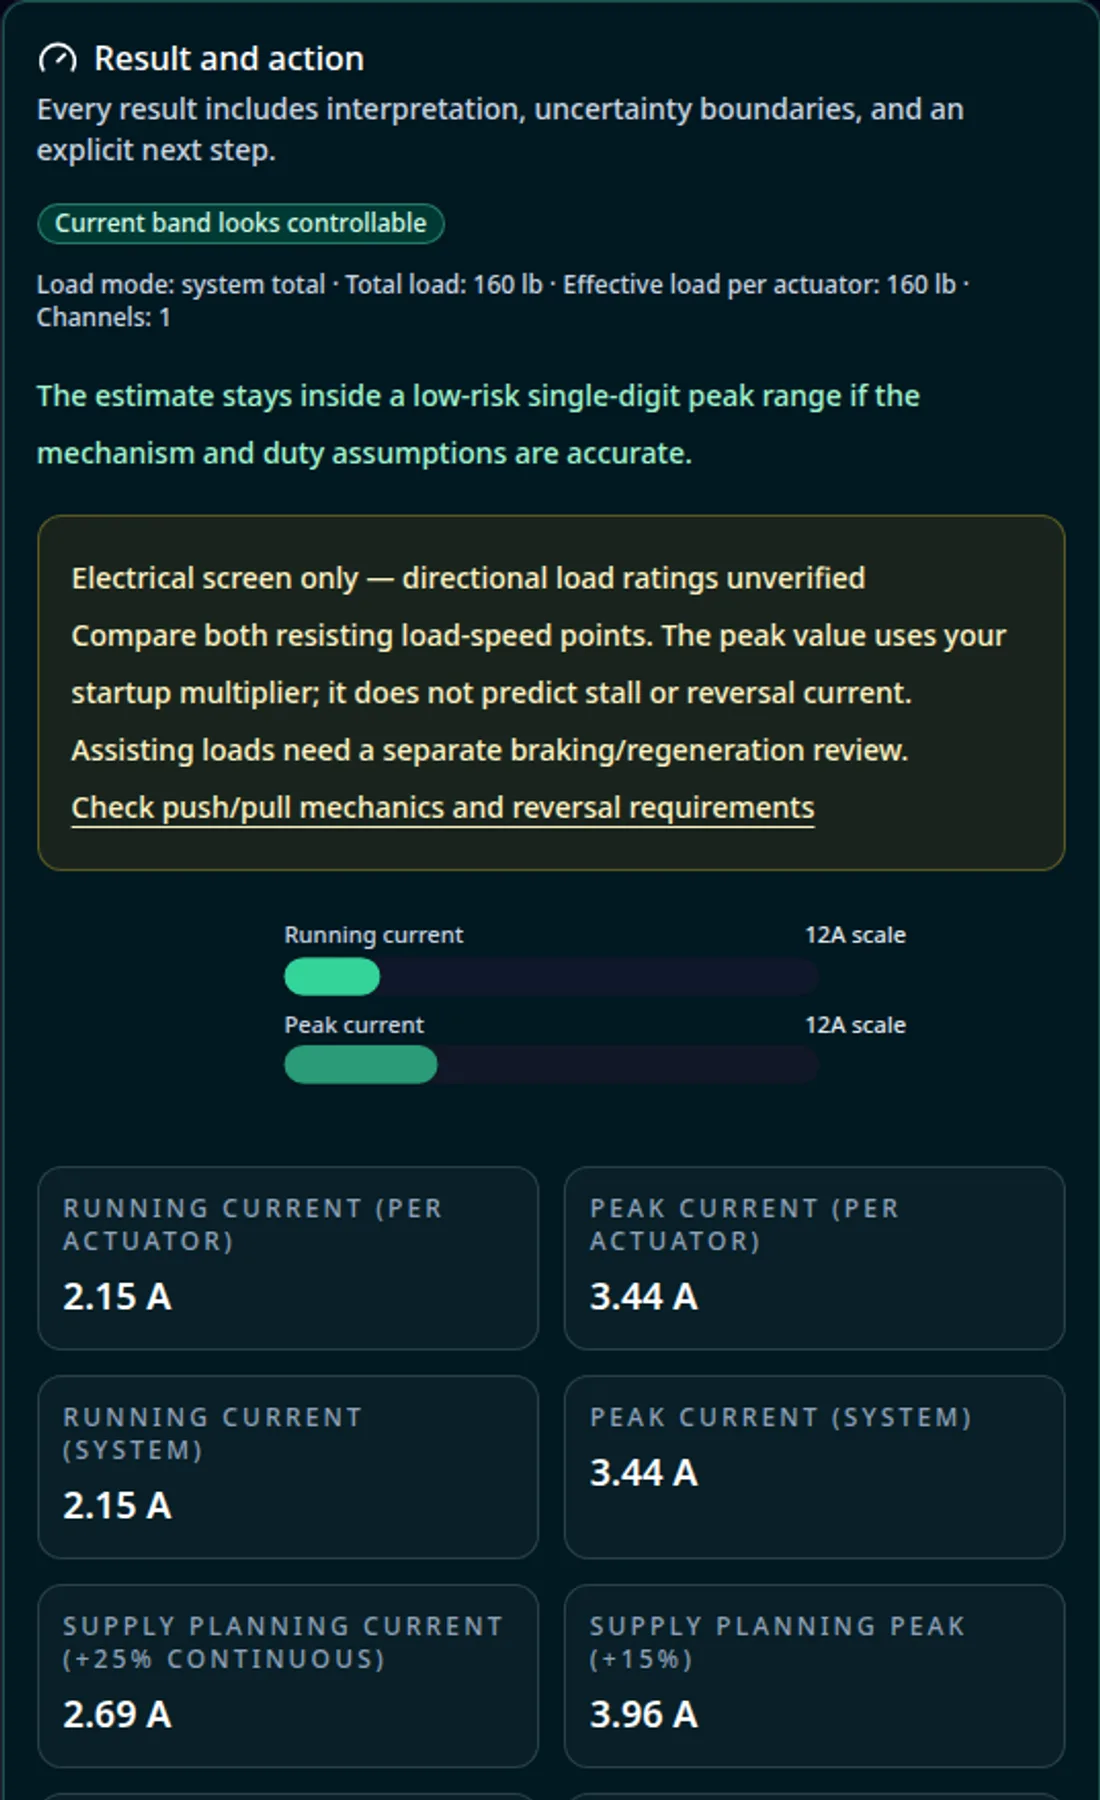
| 8-inch alias checkpoint (12V single channel) | 12V, 8 in stroke, 160 lb dynamic load, 0.55 in/s, 25% duty, 35% efficiency, 1.6x startup multiplier, 7 ft harness. | Run 2.37 A, peak 3.79 A, supply target 2.96 A continuous / 4.36 A peak, harness-risk index 1.91. | The phrase "12 volt linear actuator 8 inch stroke" maps to the canonical sizing flow: stroke is fixed, but electrical class still depends on force-speed and model family. | S38, S39, S40, S41 |
| 2-inch alias checkpoint (12V compact stroke) | 12V, 2 in stroke, 90 lb dynamic load, 0.35 in/s, 20% duty, 35% efficiency, 1.6x startup multiplier, 5 ft harness. | Run 1.08 A, peak 1.73 A, supply target 1.35 A continuous / 1.99 A peak, harness-risk index 0.61 before model-specific catalog override. | The phrase "12v linear actuator 2 inch stroke" maps to a compact-stroke screening case, but catalog rows can override the simple estimate: public 2 in / 50 mm examples show 3.2 A to 27 A max-load current. | S15, S116, S117 |
| Voltage swap check (24V same mechanical demand) | 24V with the same 180 lb and 0.50 in/s demand, 25% duty, 35% efficiency, 1.4x startup, 8 ft harness. | Run 1.21 A, peak 1.69 A, supply target 1.51 A continuous / 1.95 A peak, harness-risk index 0.56. | Current and harness risk drop materially at 24V in this profile, but family-level validation is still required. | S8, S13 |
| Dual synchronized profile (system-level check) | 12V, 240 lb shared load, 0.45 in/s, 20% duty, 35% efficiency, 1.6x startup, 10 ft harness, dual channel. | Per channel run 1.45 A and peak 2.32 A; system run 2.91 A and peak 4.65 A; supply target 3.63 A / 5.35 A. | Dual-channel requests must size upstream supply, fuse, and connector stack to system peak, not per-channel current. | S7, S9, S10 |
| Connector-loop budget check (high-current boundary) | 12V per-channel peak at 25.0 A, with four-contact loop screening budget and 10 mOhm max per contact (TE DTP spec). | Loop resistance budget 0.04 ohm; connector-loop drop 1.00 V; connector-loop power loss 25.0 W at peak. | Current-class pass and low-loss pass are separate checks. Connector-loop drop can consume meaningful low-rail margin in high-current channels. | S33 |
| Regulated 12V supply overload-window check (example profile) | MEAN WELL LRS-350-12 published values: 12V/29A rated output and overload window 105%-150% with 1-second shutdown/recover behavior. | At 150% of rated current, transient ceiling is about 43.5 A for the documented short overload window; sustained lock-load beyond that can force restart behavior. | Nameplate current is necessary but not sufficient. Release decisions must include startup/stall waveform compatibility with supply overload/recovery mode. | S60 |
| Relay motor-lock durability context (direction control boundary) | Panasonic TH relay motor-lock durability condition: 25A at 14VDC with 0.5 s ON / 9.5 s OFF timing. | Published electrical life is 100k operations under this defined motor-load profile, which is a different gate than resistive-load headline ratings. | If actuator direction control uses relays, lock-load cycle profile and commutation strategy must be validated as dedicated release criteria. | S61, S62 |
| PWM current-reading method gate (DC motor path) | PWM-driven actuator channel where current is checked at supply side only versus motor-side waveform with defined averaging method. | maxon notes supply current under PWM can diverge from true motor current depending on freewheel behavior; Portescap shows ripple stress can peak near 50% duty if inductance/frequency pairing is poor. | Do not freeze current margin from one ambiguous instrument readout. Lock measurement method first, then re-check supply/fuse/connector decisions. | S99, S100 |
Concept boundaries and applicability
Use this table to decide when a conclusion is trustworthy, when it breaks, and what the minimum next action is.
Review all 26 concept-boundary rows
Swipe horizontally to read all columns.
| Concept | Supported by | Applies when | Breaks when | Action |
|---|---|---|---|---|
| 12V telescopic linear actuators: envelope and buckling boundaries | Candidate geometry and uniform-column mechanics (S_TELESCOPIC_KINEMATICS, S_TELESCOPIC_BUCKLING) | Screening a nested actuator for a limited installation envelope. | Stage count or the minimum tube section is used as proof of the complete assembly rating. | Obtain closed/extended drawings and allowable load versus extension. The tool estimates electrical demand only; it does not qualify buckling, holding or lifetime. |
| 12V telescopic linear actuators: stage motion and electrical assumptions | NEFF mechanical architecture and maxon motor-data limitations (S_TELESCOPIC_SYNCHRONOUS, S_TELESCOPIC_ELECTRICAL) | Comparing synchronized and sequential motion for a specified load profile. | A fixed startup multiplier or coordinated motion is assumed to guarantee peak current or smooth speed. | Measure loaded current and speed through the full stroke; verify startup duration, control limits and supply overload behavior. |
| 12V telescopic linear actuators: guidance and environmental qualification | Thomson rod side-load guidance and LINAK guided-column example (S_TELESCOPIC_THOMSON, S_TELESCOPIC_EWELLIX_LINAK) | Evaluating eccentric, outdoor or cold-start applications. | A 24V lifting-column rating is transferred to a 12V rod, or an IP label is treated as freeze resistance. | Select an axial-only rod with external guidance or a moment-rated column. Request candidate-specific temperature, ingress and loaded cold-start evidence; no universal seal or grease prescription is established. |
| 12V screw actuator drive selection: efficiency and holding boundaries | Thomson lead-screw comparison, THK torque guidance and ASME thread geometry (S_SCREW_THOMSON, S_SCREW_THK, S_SCREW_ASME_B1_5) | Comparing a screw-driven 12V actuator at one resisting force-speed operating point. | Screw-only efficiency is entered as total actuator efficiency, or screw type is treated as proof of duty or power-off holding. | Use total motor × gearbox × screw efficiency, confirm measured current, and request model-specific duty and holding ratings. The calculator does not size a brake or qualify self-locking. |
| 12V push-pull actuator directional rating and buckling | Thomson actuator catalogue and column-strength design tool (S_PUSHPULL_1, S_PUSHPULL_COLUMN) | Designing or selecting a 12V push-pull actuator operating under bidirectional dynamic push (extension) and pull (retraction) loading. | Assuming voltage, stroke alone, or the calculator current band establishes directional load capacity. Unsupported length is not necessarily the stroke. | Obtain dynamic and static ratings in both directions for the exact model, stroke and mounting. Let the manufacturer specify compression derating and the application safety factor. |
| 12V push-pull direction-change sequence | ROHM maximum motor current explanation and TI DRV8871 sections 7.3.4 and 9.1 (S_PUSHPULL_REVERSAL, S_PUSHPULL_DRIVER) | Switching direction between push (extension) and pull (retraction) on a 12V PMDC linear actuator using DPDT switches, automotive relays, or H-bridge drivers. | Using the startup multiplier as a reversal-current prediction, or treating transistor shoot-through dead time as the mechanical stopping interval. | Follow the actuator/controller stop-or-brake sequence and interlock. Validate current decay, speed, rail voltage and regeneration under load before enabling reverse; timing and suppression depend on the system. |
| 12V push-pull limit-switch reverse path | Firgelli external limit-switch topology example (S_LIMIT_SWITCH_1); not a universal internal circuit | Starting retraction or extension directly off an open limit switch contact in a 2-wire push-pull linear actuator. | Copying an external diode topology or component rating into an actuator with a different internal circuit or electronic limit control. | Use the manufacturer wiring diagram and specified switch/diode ratings. Check reverse-start current duration, reverse voltage and thermal limits. If undocumented, request a schematic and bench validation rather than selecting from a generic voltage rule. |
| Duty-cycle claims | S1, S2, S5, S6 | Use full-load duty values only for the exact actuator family, stroke and ambient condition in the source table. | A marketing line says "up to 100%" but your application point is unspecified or above tested load. | Request model-specific duty confirmation at your duty profile and ambient temperature before BOM release. |
| Dynamic-load sizing vs static-hold claims | S17, S19 | Use dynamic push/pull and duty data for moving-load sizing; treat static-hold or safety-factor claims as separate survivability limits. | Static load, self-lock, or safety-factor language is copied into dynamic current/power assumptions. | Freeze BOM decisions on dynamic load-speed-duty rows, then verify hold/backdrive behavior as an additional separate test item. |
| Startup and inrush current | S4, S7 | Treat startup as a transient regime with potentially much higher current than running-state values. | Sizing uses running current only and ignores startup window or simultaneous channel starts. | Validate startup peaks under loaded extend/retract tests and ensure supply/wiring/protection can survive transient demand. |
| PWM motor-current measurement method | S97, S99 | If the actuator uses PWM motor control, define whether the measured channel is supply-side or motor-side and how averaging/RMS is computed. | A DC clamp or supply readout is treated as true motor current without considering PWM freewheel behavior and measurement bandwidth. | Freeze one measurement SOP (probe location, sampling bandwidth, averaging rule) before using measured current to sign off supply/fuse/connector margins. |
| 12V vs 24V rule-of-thumb | S1, S2, S5, S6 | For equivalent mechanical power and efficiency, higher voltage generally reduces line current. | Different actuator families, control electronics, or gearing are compared as if they were the same mechanical point. | Run like-for-like comparisons on the same family/configuration before final voltage architecture decisions. |
| Nominal 12V rail boundary | S3, S13 | Treat nominal 12V as a range with startup and load-dependent behavior, then verify current headroom at the lowest expected rail condition. | Design assumes fixed 12.0 V while real operation dips toward low-voltage limits in startup or cable-stressed conditions. | Bench-test peak current and reset behavior at worst-case low rail before locking power supply and protection selections. |
| Short-stroke mounting alignment and end-stop boundary | S17, S30 | For 6-inch/4-inch packaging and other short-stroke installs, keep force inline with actuator axis and control end-stop behavior via limits/control logic. | Offset linkage or bracket geometry adds radial load, or the standard actuator repeatedly runs into a mechanical block before end of stroke. | Add alignment checks and end-stop strategy to the RFQ/release checklist, then validate under full load for binding, noise, and thermal rise. |
| "Electric cylinder" alias boundary | S110, S111, S112 | The phrase is being used for a 12V rod-style linear actuator with inline clevis/rod-end loading and no direct worktable or cantilevered load. | The project has lateral load, twisting force, an off-center carried load, or a load mounted directly to a moving table without external guidance. | Request guide capacity, mounting style, rod-end requirements, and loaded alignment validation to choose between a rod-style actuator and a guided cylinder. |
| Cable-loss and resistance assumptions | S8 | Resistance-based checks should use standardized conductor classes and temperature-corrected resistance values. | Harness cross-section, temperature and return-path details are unknown. | Mark as screening-only and collect conductor specs plus temperature condition for final electrical sign-off. |
| Connector contact-resistance budget | S33 | Use explicit contact-resistance budgeting whenever per-channel current is in mid/high amp bands or voltage headroom is tight. | A 25 A class rating is treated as proof of negligible voltage loss and loop interface count is ignored. | Model at least one loop budget (contact resistance x contact count x current), then compare run/peak drop against your control-voltage margin. |
| SMPS overload mode versus startup/stall behavior | S60 | When actuator projects use regulated AC-DC supplies, include overload threshold and recovery behavior in architecture checks. | Rated-current value is treated as full startup/stall guarantee with no validation of shutdown/hiccup behavior. | Record supply overload mode (constant-current, hiccup, or shutdown-retry), then validate real startup/stall waveform against that mode before release. |
| Relay motor commutation and polarity-reversal gate | S61, S62, S63 | If relay contacts are used to switch/reverse actuator motor current, evaluate lock-load endurance, inrush stress, and suppression topology together. | Resistive-load relay assumptions are reused for bidirectional motor commutation without interlock or near-load suppression controls. | Use motor-load durability data, enforce anti-shoot-through/reversal interlock, and place suppression near the load side before approving relay architecture. |
| Self-locking and backdrive conditions | S1, S14, S18 | Interpret hold/self-lock ratings together with required electrical states and configuration choices (for example shorted motor path, geometry, or integrated brake/typekey behavior). | A catalog "self-locking" label is used as unconditional proof of static holding under all installation and power-loss cases. | Specify backdrive prevention strategy, confirm required typekey/brake configuration, and validate drift plus reverse-energy behavior under real gravity/load direction. |
| Ball-screw self-lock boundary (alias-specific) | S74, S78 | Alias intent is ball-screw-oriented (for example "12v ball screw linear actuator" or "ball screw linear actuator 12v"), and holding behavior matters in power-loss or gravity-loaded states. | Lead-screw self-lock assumptions are reused for ball-screw channels without an explicit brake or electrical hold strategy. | Document hold path (brake/short-path/controller logic), then validate reverse-drive behavior under real load direction before release. |
| Ball-screw critical-speed and buckling gate | S76, S77, S80 | Ball-screw stroke, unsupported length, or speed target is high enough that screw-shaft dynamics become a dominant constraint. | Electrical sizing passes but shaft-limit checks are skipped, or support condition assumptions differ from the installed structure. | Calculate critical speed and buckling load with final support/length assumptions, then keep working point below screening margin and validate on bench. |
| Ball-screw lifecycle comparability basis | S75, S79 | Comparing shortlisted ball-screw models for durability or maintenance interval in the same application envelope. | Stroke wording or marketing descriptors are used as life proxies without dynamic/static load-rating context. | Normalize comparisons on one L10/load-rating basis and keep rating-source assumptions visible in procurement records. |
| 2-inch/50 mm stroke equivalence and current-class boundary | S15, S116, S117 | The request says "12v linear actuator 2 inch stroke", "2 in stroke", or 50 mm-class compact travel and the user wants a quick 12V fit screen. | Stroke conversion is treated as enough evidence for supply, connector, duty, or controller selection without checking force, speed, duty, and exact model family. | Normalize 2 in to 50.8 mm, then compare model-level rows. Public examples include a 3.2 A 50 mm class and a 27 A 2 in class, so release decisions must stay tied to model current and duty data. |
| Alias intent to procurement workflow | S1, S5, S6, S13, S14 | A "12 volt linear actuator", "12 volt linear actuator 8 inch stroke", "12 volt linear actuator 6 inch stroke", "12 volt linear actuator 4 inch stroke", "12 volt electric linear actuators", "12 volt electric actuator", "12 linear actuator 12v", "12 volt actuators electric", or "12 volt dc linear actuator" query is treated as a parameter entry point for current and architecture sizing. | The RFQ only includes stroke and voltage but omits dynamic load, speed, duty and environment. | Use a minimum RFQ schema: stroke, load, speed, duty, ambient, cable length, simultaneous channels. |
| Limit switch reverse operation | The selected actuator and controller wiring diagram | The actuator uses a current-interrupting switch to stop at a travel limit. | Switch type, controller logic, or reverse-current path is assumed from another model. | Follow the exact wiring diagram and confirm switch, diode, and controller ratings before energizing the system. |
Marine, vehicle, wireless and safety-related deployments require application-specific validation beyond this current estimate. Discuss the installation and required evidence with the supplier. For ingress and corrosion selection, use the waterproof 12V actuator qualification guide.
Public benchmark layer
These rows anchor the page in published data so the checker output can be contextualized against real catalog signals.
Review all 16 public benchmark rows
Swipe horizontally to read all columns.
| Platform | Voltage | Stroke window | Force band | No-load current | Full-load current | Duty signal | Implication |
|---|---|---|---|---|---|---|---|
| RS PRO LD3 / LD3Q (datasheet) | 12V or 24V DC | 50 mm to 300 mm | 150 N to 1000 N | 0.8 A (12V LD3 rows) | 2.0 A to 2.9 A (12V LD3 rows) | 25% or 1 min continuous in 4 min | Represents a compact low-to-mid current class in common 12V geometry windows. |
| Progressive Automations PA-14 v1.03 | 12V, 24V, 36V, 48V DC | 1 in to 40 in | 35 lb to 150 lb dynamic | 1.0 A at 12V | 5.0 A at 12V | 25% (5 min on / 15 min off) | Common mid-band reference for quick screening before deeper model filtering. |
| Pololu / Concentric LACT2P-12V-5 | 12V DC | 2 in nominal stroke | 115 lb dynamic load | Not listed as separate current row in Pololu specs table | 27 A | 10% duty cycle | Direct 2-inch counterexample: compact stroke can still demand high-current controller, fuse, connector, and wiring checks. |
| Thomson LA14 50 mm examples | 12V DC | 50 mm nominal stroke | 500 N dynamic load class | Not listed as separate row on the referenced product pages | 3.2 A current signal | 10% duty cycle | Shows a lower-current 50 mm class exists, so compact stroke should trigger model comparison rather than a single default amp assumption. |
| Actuonix L12 miniature actuator (Rev F, 2019-11) | 6V / 12V DC | 10 mm to 100 mm | Up to 80 N lifted force (gearing dependent) | Not listed as a single row on the summary table | Gearing and load-curve dependent; datasheet highlights 12V stall current at 246 mA as a boundary signal | Maximum duty cycle 20% | Shows a sub-amp 12V micro class exists, reinforcing that current assumptions must start from family class, not keyword phrasing. |
| TiMOTION TA2 series (version 20240617-W) | 12V / 24V / 36V / 48V DC options | 20 mm to 1000 mm (code dependent) | 120 N to 1000 N | 24V table rows around 0.6 A to 1.0 A | 24V table rows around 0.9 A to 1.8 A; note indicates about 2x current when using 12V motor option | 25% duty table basis with stable 24V supply condition | Useful for showing same-code voltage scaling risk before reusing 24V current assumptions on 12V projects. |
| Schaeffler / Ewellix CAHB series (LA 1, June 2026) | 12V / 24V / 48V DC and AC families | 50 mm to 700 mm (family dependent) | 120 N to 10000 N | Model-specific tables provided by family and force code; cannot be generalized across the series | Examples include CAHB-10A around 2.8-4.4 A (12V) and CAHB-20A around 14-16 A class (12V) at rated load | Duty definitions include 10%, 20%, and 25% depending on family/load conditions | Demonstrates large current spread inside one vendor ecosystem and reinforces family-level rather than keyword-level sizing. |
| LINAK LA36 data sheet + user manual (web copy dated 2025-03-06) | 12V, 24V, 36V, 48V | Up to 1200 mm | Family and spindle-dependent | Gear/spindle-specific curves | Standard platform max current table: 26/13/10/8 A (12/24/36/48V) | Full-load duty at 40 C: 20% (<=600 mm), 15% (601-999 mm), 10% (1000-1200 mm); full performance in user manual is bounded to +5 C to +40 C | Shows stroke-tier duty limits, high-current classes, and explicit ambient boundaries; static safety-factor language must not be used as dynamic-duty permission. |
| Thomson Electrak XD | 24V and 48V DC | Up to 1200 mm | Up to 25000 N dynamic | Published as a combined no-load/max-load line (24VDC/30A, 48VDC/15A) on product page table | Published as a combined no-load/max-load line (24VDC/30A, 48VDC/15A) on product page table | 45% full-load duty at 25 C; feature highlight says up to 100% by load condition | Heavy-duty class where 24V can still demand high current and duty claims are condition-bound. |
| Thomson Warner B-Track K2 (K2XP1.0G30-12V-24) | 12V DC | 24 in nominal stroke | 12460 N dynamic | Not published as separate row on product page | Maximum current draw listed as 25.0 A | Model-specific, confirm from product family table and application profile | Direct counterexample to low-amp assumptions for 12V heavy-load designs. |
| Thomson Electrak 050 (DE12-17W41-08FNMHN) | 12V DC | 8 in nominal stroke | 112 lbf dynamic | 1.5 A | 4.0 A | 25% duty | 8-inch can still map to a low-current class when force/speed class is light. |
| Thomson Electrak 10 (D12-20B5-08) | 12V DC | 8 in nominal stroke | 1000 lbf dynamic | 0.4 A | 14.0 A | 25% duty | Same 8-inch stroke can shift into mid/high current class under higher-load gearing. |
| Thomson Electrak 10 high-speed (D12-05B5-08) | 12V DC | 8 in nominal stroke | 500 lbf dynamic | 0.6 A | 28.0 A | 25% duty | At the same 8-inch stroke, high-speed setup can push max-load current to 28 A, stressing supply and connector margins. |
| Thomson Electrak 10 (D12-20B5-06) | 12V DC | 6 in nominal stroke | 1000 lbf dynamic | 0.4 A | 14.0 A | 25% duty | Provides a mid/high-current 6-inch checkpoint; short stroke still needs full model-level power-stage screening. |
| Thomson Electrak 10 high-speed (D12-05B5-06) | 12V DC | 6 in nominal stroke | 500 lbf dynamic | 0.6 A | 28.0 A | 25% duty | Shows 6-inch high-speed classes can reach 28 A channel stress, similar to larger-stroke high-current profiles. |
| Thomson Electrak 050 (DE12-17W41-04NPHHN-DA) | 12V DC | 4 in nominal stroke | 112 lbf dynamic | Not published as separate row on product page | Maximum current draw listed as 3.8 A | 25% duty | 4-inch can be low-current class electrically, but the same row lists dynamic ingress as N/A while static ingress is IP56, so waterproof interpretation still needs a moving-duty gate. |
Counterexamples and limit cases
These rows show why one-size claims fail. Actuators with the same voltage or stroke can still have very different electrical ratings.
Review all 12 counterexamples
Swipe horizontally to read all columns.
| Scenario | Evidence | What it shows | Decision impact |
|---|---|---|---|
| Illustrative counterexample: high-lead Acme actuator assumed to self-lock | Hypothetical design check, not a field incident: for lead angle 14° and effective friction angle 9°, the lead exceeds friction angle, so a static friction model does not predict self-locking. Thomson states that holding depends on lead and lubrication (S_SCREW_THOMSON). | Acme or single-start wording does not establish an unpowered holding rating; vibration, lubrication and wear require separate validation. | Obtain the rated holding limit and use a rated power-off brake or independent restraint where movement is hazardous. |
| Micro 12V class versus heavy 12V class under one keyword | Actuonix L12 datasheet lists 12V stall current at 246 mA, while Thomson K2 12V model page lists maximum current draw at 25.0 A. | Two products both labeled as 12V linear actuators can differ by more than 100x in current signal. | Keyword-level assumptions cannot set power architecture; family and load class must be identified first. |
| Low-force compact actuator class | RS PRO LD3 12V rows show 0.8 A no-load and 2.0-2.9 A full-load with 25% duty. | Single-digit amps are plausible in lower-force classes near common 12V selection checkpoints. | A 5 A supply might be sufficient for this class with proper transient margin and wiring checks. |
| Same model code but different motor voltage | TiMOTION TA2 table is measured at stable 24V and a datasheet note states 12V versions can keep similar speed with about double current consumption. | Current translation from 24V to 12V is not neutral, even when mechanical performance target appears similar. | Do not copy 24V current rows into 12V power-stage design without explicit voltage-scaling correction. |
| Same 8-inch stroke but different model classes | Thomson 12V examples at 8 in stroke span 1.5/4 A (Electrak 050 DE12-17W41-08FNMHN), 0.4/14 A (Electrak 10 D12-20B5-08), and 0.6/28 A (Electrak 10 D12-05B5-08) current rows. | Even with identical 8-inch travel, current class can shift drastically with load class and speed gearing. | Do not size supply and connector stack from stroke phrase alone; compare model-level current and duty rows first. |
| 2-inch/50 mm compact stroke but different electrical class | Pololu/Concentric LACT2P-12V-5 lists 2 in stroke, 12V, 115 lb dynamic load, 0.28 in/s full-load speed, 10% duty, and 27 A full-load current; Thomson LA14 50 mm 12V examples list 500 N, 3.2 A current, and 10% duty. | A compact 2-inch/50 mm stroke request can still sit in either low single-digit current or high-current controller territory depending on force and gearing. | Do not select a 5 A supply, switch, fuse, or connector only because the stroke is short; verify the exact model current and travel-rate row before RFQ freeze. |
| Contact current class passes but contact-loop voltage budget still fails | TE DTP specification 108-151012 Rev C lists 25.0 A class current and 10 mOhm max contact resistance. A four-contact loop budget is about 1.0 V drop at 25 A. | Connector current-capacity checks and connector-loss checks are separate and both are needed in high-current 12V architectures. | Include contact-loop resistance budgeting before freezing connector and low-rail control margins. |
| Static safety-factor misused as dynamic motion margin | LINAK LA36 user manual states safety factor 2 for static-load survivability, while the same manual still enforces dynamic duty windows and ambient constraints. | Static withstand and dynamic thermal-motion capability are separate boundaries that should not be merged. | Use dynamic load-speed-duty evidence for current sizing, then run separate static-hold/backdrive validation for safety cases. |
| Nominal 12V assumed as fixed 12.0 V | Thomson K2 model page lists operational range 10-16 VDC and max current draw 25.0 A. | Supply-rail variation is part of real operation, not an exception, and it affects startup margin and fault behavior. | Validate at low-rail and loaded startup conditions, not only at a clean 12.0 V lab point. |
| 4-inch stroke package but radial side load from linkage offset | LINAK LA36 manual guidance states do not side-load and warns standard variants are not allowed to run into a mechanical block before end of stroke; Thomson side-loading guidance links radial loading to binding and potential damage. | Short stroke does not automatically reduce mechanical risk if mounting geometry applies radial force. | Treat alignment and end-stop control as release criteria, not post-install tuning. |
| 29 A nameplate supply assumed to cover all actuator startup events | MEAN WELL LRS-350-12 lists 29 A rated output and overload behavior in a 105%-150% window with 1-second shutdown/recovery behavior. | Rated current and startup survivability are separate checks; overload recovery behavior can become the real limit during hard starts or jams. | Validate startup/stall current-time waveform against supply overload mode before freezing architecture. |
| Relay reversal designed from resistive-load assumptions | Panasonic TH relay data publishes dedicated motor-lock durability conditions, and Panasonic/Omron cautions describe high motor inrush and inductive-arc limits with suppression/interlock constraints. | Motor commutation stress differs from resistive switching and can dominate relay lifecycle in bidirectional actuator control. | Use motor-load durability and suppression/interlock validation before approving relay-driven direction control. |
Option comparison
Use this matrix when the calculated amps are acceptable but architecture tradeoffs remain open.
Review all 24 option comparisons
Swipe horizontally to read all columns.
| Option | Where it wins | Where it breaks | Current signal | Best for |
|---|---|---|---|---|
| 12V Push-Pull Actuator (Bidirectional Electromechanical) vs Single-Direction (Spring/Gravity Return) | Provides powered extension and retraction. Position feedback and unpowered holding require explicit model ratings; they are not guaranteed by bidirectional operation. | Requires a compatible reversing control architecture. Compression, mounting, holding and any fail-safe return require separate model-level checks; a powered push-pull model does not imply automatic return after power loss. | Current depends on each directional load-speed point and the selected motor/drive. Measure startup and reversal peaks separately; the checker startup multiplier is only a screening assumption. | Industrial automation, dual-acting hatches, throttle valves, solar tracking, and applications requiring controlled powered extension and powered retraction. |
| 12V Electric Actuator (Electromechanical Ram) vs Hydraulic Ram | Compare the two architectures using the same force, speed, duty cycle, holding requirements, and full-cycle energy boundary. | This page cannot size hydraulic pressure, flow, valves, pump capacity, or hydraulic safety controls. | Electrical current estimates apply only to the electric actuator. Hydraulic input power must be measured or specified separately. | Use when screening an architecture choice; finish each side with model- and application-specific data. |
| Stay on 12V single actuator architecture | Simpler low-voltage integration when load class is genuinely low and cable runs are short. | High-force 12V variants can move into 20 A+ territory and stress connectors, protection and harness. | Current stress can be highest in this option for equivalent power. | Compact to moderate-load use cases with controlled transient demand. |
| Move to 24V architecture on equivalent mechanical point | Lower line current for similar power, usually better cable-loss tolerance and protection margin. | Does not guarantee low current if actuator class itself is high-force/high-power. | Lower than 12V for like-for-like power, but not universally low across families. | Installations near 12V supply/wiring limits or longer harness runs. |
| Keep 12V bus but route brushed vs brushless DC motor explicitly | Lets teams match maintenance strategy and speed-control precision to the application instead of defaulting to one motor class. | Ignoring PWM ripple, thermal load, and maintenance constraints can erase initial cost advantages and create late redesign cycles. | Brushed designs can be sensitive to PWM ripple and commutation wear, while brushless packages can provide tighter speed control with added electronics complexity. | Projects where "dc motor" intent is explicit and lifecycle/service model matters as much as initial current sizing. |
| Keep 12V bus but enforce low-rail and drop-class verification | Preserves existing 12V ecosystem while reducing late surprises from rail sag and cable-loss under startup load. | Still vulnerable if family selection is wrong or if compliance mapping is skipped for critical circuits. | Current envelope can remain acceptable only when worst-case rail and conductor assumptions are validated. | Retrofits constrained to 12V where rewiring/regulation changes are limited but validation budget exists. |
| Keep 12V and reduce connector-interface resistance path | Can recover low-rail margin without voltage-architecture migration by controlling contact count and contact-loss budget. | Does not solve wrong actuator-family selection or missing startup/transient validation. | Current stays the same, but connector-loop voltage loss can drop materially if resistance budget and interface topology are improved. | 12V platforms where connector-chain voltage loss is the dominant margin limiter. |
| Keep 12V but upsize conductor/OCP stack with Table 5 corrections | Improves thermal and protection margin without changing the bus voltage architecture. | Adds cable cost/space and still requires domain scope and ignition-protection checks in marine fuel-hazard areas. | Load current is unchanged, but allowable branch envelope and nuisance-trip resilience improve when corrected ampacity math is applied. | Marine and retrofit projects where 12V is fixed but branch protection is near limits. |
| Static-only ingress claim versus dynamic-rated ingress claim | Static-only claim can look cheaper and easier to source when exposure assumptions are limited to enclosure-at-rest conditions. | If the rod moves during spray/washdown, static-only claims can leave motion-state ingress risk unqualified. | Current math is unchanged, but moving-duty reliability and requalification risk diverge sharply. | Use static-only claims only for clearly bounded dry/intermittent exposure; use dynamic-rated evidence for moving waterproof duty. |
| Rod-style 12V actuator vs guided electric cylinder | Rod-style keeps cost, wiring, and packaging simpler when the load is inline and externally guided; guided-cylinder architecture handles lateral or twisting loads more directly. | Rod-style selection breaks when the actuator rod or seals become the load-bearing guide. Guided variants add cost, length, controller complexity, and model-specific guide-capacity validation. | Current math can look identical at first pass, but side-load tolerance, alignment procedure, and guide wear risk diverge materially. | Use rod-style for inline push/pull with separate guidance; use guided cylinder or slide-table architecture when load centering and anti-rotation are not guaranteed. |
| Use high-duty smart actuator family | Better diagnostics and some families with higher duty capability under defined load conditions. | Cost and integration complexity increase; marketing-level duty claims are not blanket approvals. | May still demand high absolute current in high-load classes. | Duty-critical systems with clear control and validation budgets. |
| 12V vehicle feed with load-dump cutoff/clamp front-end | Preserves 12V architecture while adding resilience against high-energy vehicle transients. | Adds protection components, calibration effort, and pulse-validation work before release. | Steady-state current is unchanged, but transient survival margin improves materially. | Road-vehicle battery/alternator domains where actuator control electronics share the main bus. |
| Vehicle EMC signoff: emission-only vs emission+immunity route | Emission-only path can appear faster in early prototyping; dual-route signoff reduces late failure risk by covering both emitted-noise and susceptibility behavior. | Emission-only closure can miss immunity-driven malfunctions; dual-route adds test planning and documentation effort. | Load current math is unchanged, but release risk shifts materially when immunity evidence is missing. | Vehicle programs that must avoid late EMC redesign by locking CISPR 25 + ISO 11452 checkpoints before RFQ freeze. |
| EU 12V compliance route with explicit LVD/EMC split | Prevents scope confusion by documenting that 12V DC may sit below LVD thresholds while EMC controls still apply to relevant equipment. | Adds documentation and test-traceability effort; cannot be handled by copying a single high-voltage checklist. | Electrical current sizing is unchanged, but release risk drops when directive routing and EMC evidence are explicit. | EU-bound actuator assemblies where compliance review must be repeatable across product variants. |
| US prototype/demo-only import path vs controlled pre-sale import path | Prototype/demo path can simplify early validation logistics; controlled pre-sale import path supports channel stocking before final grant when governance is mature. | Using pre-sale scale without 2.1204 quantity/label/record controls can trigger preventable launch blockers even if Part 15 route is known. | Electrical current math is unchanged, but market-entry schedule risk diverges sharply across import-condition paths. | Wireless SKUs that need staged US launch should map import mode early and lock compliance ownership before distributor activity begins. |
| 8-inch high-speed setup vs 8-inch high-force setup | High-speed setup shortens travel time for the same stroke; high-force setup lowers mechanical strain at heavier loads. | High-speed 8-inch variants can demand much higher peak current, while high-force gearing can reduce throughput and cycle speed. | Published 8-inch examples span 4 A, 14 A, and 28 A max-load rows across model classes. | Projects that have fixed 8-inch travel but can still choose between throughput-biased and force-biased architectures. |
| 12V battery-capable bus vs hiccup-style regulated SMPS | Battery-capable buses usually tolerate short startup surges better; regulated SMPS can improve steady-state voltage quality and integration. | If SMPS overload behavior is not matched to startup/stall profile, restart/hiccup cycles can appear even when rated current looks sufficient. | Current demand is unchanged at the load, but available transient window can differ materially by supply protection mode. | Projects choosing between battery-like transient tolerance and compact AC-DC conversion architectures. |
| Relay polarity reversal vs electronic H-bridge direction control | Relay solutions can be simple for low-cycle systems; electronic drivers can improve switching control and fault observability. | Relay commutation under motor lock/inrush can reduce life quickly if interlock and suppression design is weak. | Peak current remains load-driven, but switching stress and fault behavior differ by commutation architecture. | Teams that can validate direction-switching behavior under real motor load before release. |
| Design review without recall-mode checklist vs recall-informed checklist | Skipping recall-mode review can shorten early documentation time; recall-informed review catches control-board/wiring risks earlier. | No-checklist route can miss known hazard patterns that passed initial current sizing but later triggered field recalls. | Current calculations may still pass in both routes, but release risk diverges when control-board thermal and wiring-integrity gates are omitted. | Production-intent launches should use recall-informed review; no-checklist route is only defensible for internal prototypes with no market exposure. |
| Ball-screw channel without hold brake vs brake-enabled hold architecture | No-brake path can reduce part count and standby complexity; brake-enabled path improves hold control in gravity or power-loss scenarios. | No-brake assumptions can fail when backdrive risk is non-negligible; brake-enabled path adds control logic and release-validation effort. | Running-current math may look similar, but hold-state risk and restart behavior diverge materially. | Use no-brake only when reverse-load behavior is verified safe; use brake-enabled path when hold integrity is a release-critical requirement. |
| Long unsupported screw at higher speed vs shorter/stronger support configuration | Higher speed can improve cycle time; shorter/stronger support raises dynamic margin against shaft limits. | Aggressive speed with long unsupported length can breach critical-speed or buckling margins even if electrical limits pass. | Current estimation can remain acceptable while mechanical shaft limits fail, so both gates must be closed together. | Ball-screw projects where stroke and throughput are both strict and support geometry can be engineered deliberately. |
| RAM upfitter branch versus dedicated external power branch | Factory upfitter branches can reduce integration effort when documented branch limits and fuse-position rules are respected. | High-current duty can exceed branch-continuous limits or land on pass-through circuits (14 A/21 A/28 A classes) that do not match actuator startup profile even if fuse-slot labels look large. | Published RAM documents separate fuse rating from allowable continuous draw and also split pass-through circuits by function/current class, so branch validation needs both tables plus switch-mode assumptions. | Truck upfit projects that can map actuator duty to published auxiliary-branch constraints before procurement freeze. |
| Treat "ram" wording as hydraulic category by default | Can be valid when project truly uses hydraulic fluid-power actuators and associated safety framework. | Misroutes electric 12V sizing projects and can add wrong assumptions about branch architecture, leakage risk, and safety obligations. | Current math and protection strategy differ materially between electric 12V screw actuators and hydraulic fluid-power systems. | Projects that explicitly confirm hydraulic architecture; otherwise run domain routing before using this branch. |
| Dual-actuator load sharing | Can reduce per-channel current if load split and synchronization are robust. | Total system peak can still be high, and sync faults create asymmetric overload risks. | Lower channel current does not automatically mean lower system peak requirement. | Wide structures that require two lift points regardless of electrical benefits. |
Protection stack checks
Check supply overload and recovery, relay direction changes, dynamic and static load limits, connectors, fuses, inrush and backdrive before approving the electrical architecture.
Review all 12 protection-stack checks
Swipe horizontally to read all columns.
| Control layer | Verified data | Decision boundary | Failure if ignored | Evidence |
|---|---|---|---|---|
| 12V screw actuator holding and thermal protection gate | THK describes conversion from axial thrust back to rotation. Thomson ties actuator duty to load, ambient temperature and maximum on-time; neither source establishes a universal screw-class duty rating. | Confirm power-off holding, brake location and minimum rated torque with the supplier. Obtain duty and thermal-protection limits for the selected complete actuator. | An unrestrained load may move after power loss; a motor or nut may overheat even when the current screen looks acceptable. | S_SCREW_THOMSON, S_SCREW_THK, S_SCREW_DUTY |
| Dynamic-vs-static load classification gate | LINAK LA36 user manual states safety factor 2 for static-load survivability while keeping dynamic duty and ambient limits explicit; Actuonix L12 datasheet separates static/backdrive and motion parameters. | Do not convert static-hold or safety-factor numbers into dynamic current-sizing allowances without model-level dynamic validation. | Power stage appears sufficient in paperwork but overheats or stalls when real dynamic duty is applied. | S17, S19 |
| Short-stroke side-load and end-stop gate | The LA36 user manual states "Do not sideload the actuator" and warns standard versions are not allowed to run into a mechanical block before end of stroke; Thomson side-loading guidance explains radial load can cause binding and damage. | For compact 6-inch/4-inch packaging, do not approve release until alignment and end-stop controls are validated under loaded motion. | Binding, premature wear, or hard-stop shock can invalidate otherwise correct current sizing. | S17, S30 |
| "12v electric cylinder actuator" rod-vs-guided gate | SMC describes rod/guided-rod electric actuators as separate use cases: rod-style for straight-line pushing/pulling/lifting/pressing, guided-rod style for lateral loads or rotational forces; SMC guided-cylinder pages isolate load bearing from rod/seal motion with internal guide shafts. | Do not approve a plain rod-style 12V actuator when the actuator body is expected to carry lateral, twisting, or worktable loads without external guidance. | Electrical sizing can pass while rod bending, seal wear, binding, or worktable deflection becomes the actual field failure. | S111, S112 |
| PWM motor-current measurement-method gate | maxon support guidance states supply-side current under PWM can differ from true motor current and provides method-dependent conversion formulas; Portescap guidance adds ripple-driven thermal implications when PWM design is not controlled. | Before freezing power, fuse, and connector limits in DC-motor projects, lock one measurement SOP (probe point, bandwidth, averaging basis) and keep it consistent across validation runs. | Teams can sign off conflicting current numbers from different instruments/probe points and lock the wrong electrical margins. | S99, S100 |
| Connector channel capacity | TE DEUTSCH DTP sources include catalog current-class guidance (25 A for size 12 contacts with 10-14 AWG) and a performance specification that also limits contact resistance to 10 mOhm maximum. | If computed per-channel peak current approaches or exceeds 25 A class, escalate connector/contact architecture before release. | Contact heating, voltage drop drift, and intermittent high-load starts even when headline current rating appears acceptable. | S9, S33 |
| Fuse behavior at startup and temperature | Littelfuse ATOF time-current and derating tables show 200% current can survive up to seconds and 30 A nominal maps to 15 A at 125 C typical derating. | Do not treat nominal fuse label as continuous allowable current in high ambient or repetitive startup profiles. | Nuisance trips in field use or delayed fault clearing during overload. | S10 |
| Upstream SMPS overload and recovery-mode gate | MEAN WELL LRS-350-12 specification lists 12V/29A rated output with overload behavior in the 105%-150% range and a 1-second shutdown/recovery behavior window, plus end-equipment integration notes. | Do not release startup/stall-sensitive designs from rated-current value alone; include supply protection mode and restart behavior in validation criteria. | System can oscillate into shutdown/restart under motor launch or jam conditions even though steady-state current arithmetic appears acceptable. | S60 |
| Relay commutation and direction-change gate | Panasonic TH relay data provides motor-lock durability windows distinct from resistive load ratings, while Panasonic/Omron relay cautions flag high inrush and inductive-arc limits with explicit suppression/interlock guidance. | When relays switch actuator motor direction, require motor-load life evidence, anti-shoot-through direction logic, and near-load suppression strategy before release. | Direction changes can cause contact welding/chatter, shortened relay life, and unstable motion even when nominal current class seems sufficient. | S61, S62, S63 |
| Inrush characterization method | TI application guidance states startup inrush is high without back-EMF and provides a repeatable resistance estimate path using voltage and stall current. | Require at least one loaded startup measurement campaign before finalizing multiplier, fuse and supply sizing. | The design may pass average-current checks but fail at launch or restart events. | S7 |
| Backdrive and reverse-energy handling | LA36 notes maximum self-locking behavior depends on shorting motor poles and warns soft-stop release from mechanical block can generate high-voltage pulse (load dump). Current Schaeffler CAHB tables define holding force as powered-down static holding; its selector separately warns that self-locking may depend on brake/typekey configuration. Do not transfer one model’s electrical holding conditions to another. | For gravity-assisted or over-running loads, define brake/short-path strategy and transient suppression before releasing wiring and control architecture. | Unexpected drift/backdrive, controller resets, or component stress from reverse-energy pulses. | S1, S14, S18 |
| Ball-screw critical-speed and buckling gate | Thomson training pages provide explicit critical-speed and column-buckling equations with 80% screening guidance, and NSK SS-series catalog tables show permissible-rpm sensitivity to unsupported length and support arrangement. | Do not approve high-speed or long-stroke ball-screw channels from current math alone; close speed/compression gates with installed support assumptions first. | Shaft whip, vibration, compression instability, or premature wear can appear even when electrical current and thermal checks are nominal. | S76, S77, S80 |
Risk controls
The highest-impact mistakes come from startup, cable, and duty assumptions. Keep mitigation actions explicit in the RFQ package.
Review all 10 risk-control rows
Swipe horizontally to read all columns.
| Risk | Impact | Warning sign | Mitigation |
|---|---|---|---|
| Kit power supply undersizing | Voltage sag, jerky movement, or complete SMPS shutdown during motor startup or heavy loads. | Actuator stutters or stops when loaded, despite running fine without load. Power supply LED flickers or dims. | Measure peak current demand (inrush/stall) and ensure the selected or bundled supply rating exceeds this peak, not just the nominal running current. |
| Bracket misalignment in kits | Side loading can accelerate wear or failure in the lead screw, bearings, dynamic seals, and mounting brackets. | Grinding or squealing noises during travel, uneven extension speed, or visible rod deflection. | Use the selected clevis hardware loosely during initial cycling to check alignment before final torque. Ensure the load travels parallel to the actuator axis. |
| Power stage sized by running current only | Brownout, reset, or start failure during loaded launch. | Bench pass at steady motion but repeatable startup failures in installed mechanism. | Design against transient current evidence, then verify with loaded startup waveforms on all active channels. |
| Using PWM supply current as if it were true motor current | Current margin can be overstated or understated, leading to wrong fuse, connector, and power-supply decisions. | Different instruments or probe locations produce conflicting current readings for the same motion cycle. | Define and document one measurement SOP (probe location, bandwidth, averaging rule) before freezing RFQ electrical limits. |
| Treating duty cycle as one universal number | Unexpected thermal accumulation, shortened life, and intermittent shutdown under repetitive cycles. | Housing temperature climbs cycle-to-cycle even when instantaneous current appears acceptable. | Map your stroke/load/ambient to the specific family duty table and request written model-level confirmation. |
| Assuming low temperature behaves like room temperature | Cold-start overcurrent and protection trips in field deployment. | Cold-weather start draws materially higher current than lab baseline. | Test worst-case ambient and include seasonal current envelope in supply and fuse decisions. |
| Treating nominal 12V as a fixed rail during startup | Undersized supply margin, control resets, and inconsistent startup performance near low-voltage operating limits. | System works on bench at stable supply but fails intermittently when source voltage sags under real load. | Validate worst-case startup at low-rail condition and include rail tolerance in supply, fuse and cable decisions. |
| Ignoring side-load alignment in compact 6-inch/4-inch packaging | Actuator binding, uneven wear, and early mechanical failure despite apparently safe electrical sizing. | Current spikes and motion noise increase near travel ends after bracket/linkage integration. | Keep force inline, control end-stops, and run loaded alignment checks before release. |
| Treating "12v electric cylinder actuator" as wording only | A plain rod actuator can be selected for a guided-cylinder job, causing rod/seal wear, binding, or unstable positioning even when current and duty estimates pass. | The RFQ mentions off-center loads, twisting forces, a moving table, direct load carriage, or no separate guide rails, but the BOM still lists a standard clevis rod actuator. | Route the job through a rod-vs-guided gate and require side-load/guide-capacity evidence plus loaded alignment validation before release. |
| Copying industrial electric-actuator duty classes into small 12V selection | The project can claim standards maturity while using endurance or duty assumptions outside the cited standard scope. | ISO 22153 valve-actuator classes are referenced without a supplier model table for the actual 12V actuator family. | Use ISO 22153 as taxonomy only; freeze final duty/endurance on supplier-specific 12V current, thrust, ambient, and cycle evidence. |
Scenario examples
Each scenario includes assumptions, resulting signal, and action path so teams can compare quickly against their own application profile.
Evidence gaps and pending items
Where reliable public data is still incomplete, this section avoids hard conclusions and provides a minimum executable validation path.
Review all 11 evidence gaps
Swipe horizontally to read all columns.
| Claim area | Current public evidence | Status | Minimum executable path |
|---|---|---|---|
| Universal vibration self-locking cutoff for Acme screw actuators without dynamic testing | Lead and friction affect static self-locking, but no universal vibration derating or safe lead-angle threshold is established here. Candidate-specific holding data is missing. | partial | Obtain rated power-off holding and validate the loaded axis with the required restraint and power-loss tests before release. |
| Universal continuous/peak supply headroom margin | The checker adds 25% to estimated continuous current and 15% to estimated peak current as planning defaults. These increments are not established here as universal standards or supplier requirements. | partial | Use the selected power supply and controller overload/recovery limits, then verify the actual loaded startup waveform and rail behavior before final sizing. |
| Universal startup multiplier for all linear-actuator families | There is no single cross-vendor multiplier. The current Thomson Electrak HD manual lists up to 2x or 4x rated current by control option for 75-150 ms; Thomson catalog guidance also gives a 3x Electrak MD example. Neither figure is a universal actuator limit. | partial | Use the exact shortlisted actuator series, control option, and load to read its manual limits. Treat the checker multiplier as an editable estimate, not an approval; capture loaded startup current traces before locking project-specific margins. |
| Direct voltage-drop percentage from this checker output | The current tool uses a harness-risk index because conductor class/cross-section and thermal condition are not yet captured as inputs. | partial | Add conductor cross-section and temperature inputs, then compute loop resistance with standardized tables before using drop % as a release metric. |
| One duty-cycle number for all 12V applications | Public sources show duty varies heavily by ambient temperature. For example, LINAK LA12 data specifies max 20% duty cycle at 0-20°C, with decreased duty at higher temperatures. There is no single universal value. | partial | Bind RFQ approval to model-specific duty table row plus your real cycle profile and actual ambient envelope (e.g. accounting for >20°C derating). |
| Bidirectional equivalence of extend/retract peak current | Many public sheets provide envelope tables but not complete extend/retract transient traces for each configuration. | pending - no reliable public dataset | Run instrumented extension and retraction tests at target load and voltage before acceptance. |
| Cross-vendor connector and fuse coordination envelope for each actuator family | Public sources now provide contact-current and contact-resistance limits plus fuse derating curves, but no single open dataset maps these against per-model startup waveforms and interface topology. | partial | Create project BOM-level matrix linking selected connector, fuse, cable and measured startup waveform; approve only combinations that pass thermal and transient tests. |
| Cross-vendor quantitative side-load limits for 6-inch/4-inch linkage geometries | Public guidance clearly warns against side loading, but open cross-vendor datasets rarely publish directly comparable radial-load limits for each mounting geometry and stroke code. | pending - no reliable public dataset | Define linkage geometry and side-load vectors, then run model-level validation with supplier guidance and loaded endurance checks. |
| Open cross-vendor guide-capacity equivalence for "12v electric cylinder actuator" searches | SMC and Kollmorgen provide strong qualitative boundaries for rod/guided selection and alignment, but no reliable open dataset normalizes side-load, moment-load, guide life, and 12V current across competing cylinder-style actuator families (暂无可靠公开数据). | partial | For each shortlisted electric-cylinder family, request model-specific side-load/moment ratings, mounting-style limits, alignment procedure, and loaded cycle validation before treating options as interchangeable. |
| Cross-vendor startup survivability mapping by supply overload mode (constant-current vs shutdown/hiccup) | Public supply datasheets expose overload thresholds and recovery behavior, but open datasets rarely map actuator startup/stall waveforms against multiple PSU recovery modes in one comparable matrix. | partial | For shortlisted supplies, capture startup + jam replay current/time traces and verify pass/fail against each PSU overload and restart profile before final release. |
| Open lifecycle drift data for relay contacts in bidirectional actuator-motor commutation | Relay documentation provides motor-load durability conditions and cautions, but open cross-vendor datasets for long-run bidirectional actuator reversal duty remain limited. | partial | Build project-specific direction-reversal endurance tests (load, reversal cadence, suppression topology, ambient) and gate procurement on measured contact stability. |
FAQ
Decision-focused questions covering electrical sizing, component fit, and validation boundaries.
The word “ram” can refer to different mechanisms. Confirm the actuator type and its datasheet before using an estimate for a purchase or RFQ.
Sources and evidence boundaries
Core conclusions map to numbered sources below. Page evidence was last reviewed on 2026-11-03. Unknowns remain explicit to avoid false confidence.