12V Micro Linear Actuator Fit Check

Check a 12V mini linear actuator or micro model against cited examples. Enter your requirements to see limits and next steps.

Enter your requirements
Catalog range check only. Model fit and current need a selected SKU.

Range: 5 to 150 mm.

Range: 5 to 350 N.

Range: 1 to 40 mm/s.

Range: 5% to 80%.

Current constraints: 12V · IP54 · indoor · side load 2 N · space 110 mm. Edit below.

Send profile for review
Edit installation & environment

All fields are required for screening; these defaults are editable. Installation space is the available closed hole-to-hole span.

Range: 0 to 80 N.

Range: 40 to 500 mm.

Try a 12v mini actuator or 12v mini linear actuator example

Example only: 60 mm stroke, 55 N load, 12 mm/s, 20% duty, 6 N side load, 145 mm space, 12V, IP65, outdoor.

Your requirements review
Output shows cited-example boundary flags, missing model-specific data, and a concrete validation step.

What to check before choosing a model

Review the model-specific limits, electrical requirements and installation checks before sending an RFQ.

Published on 2026-04-22 · Last reviewed on 2026-10-22Published by Custom Linear Actuator. Source-based selection guidance; no physical actuator test is claimed.
high confidence
Choose a model by its data, not by “mini” or “micro”.

These names overlap in supplier catalogs. This checker compares individual requirements with cited examples; it does not find a SKU that meets their combined load, speed, stroke and package requirements.

Evidence: S1S2S13

high confidence
Moving load, side load and power-off holding are separate checks.

Use the selected gearing and stroke option. L12 publishes stroke-specific side-load and gear-specific back-drive limits; LINAK LA14 prohibits side loading. Thomson distinguishes industrial axial-load designs from precision models with side-load support. Static strength or speed alone cannot establish power-off holding.

Evidence: S12S13S33S35

high confidence
Size a 12V mini linear actuator harness from the chosen model’s current.

The PA-14 12V example lists 5 A full-load current; L12 lists 246 mA stall current at 12V. These are different model ratings and operating points, not mini/micro class limits. Calculate cable losses and check ampacity using the candidate’s running and startup requirements.

Evidence: S13S31S34

high confidence
Startup current and harness losses can rule out a driver.

Compare the actuator startup envelope with bridge pulse and thermal limits. Calculate loop voltage drop from the chosen cable’s resistance and current, then check ampacity, connectors and temperature separately. AWG alone does not establish suitability.

Evidence: S12S14S15S31

high confidence
Match PWM control and protection to the actual actuator interface.

Power PWM on a bare motor and logic-level position PWM are different interfaces. Use the manufacturer circuit for current recirculation and stopping; neither a generic TVS part nor 100% duty near a limit is a validated universal protection method.

Evidence: S13S14S15

high confidence
Validate duty and temperature together on the chosen model.

L12/L16 specify 20% maximum duty and LACT4 specifies 25%. IEC 60085 classifies insulation thermal endurance; its public scope does not provide a 50% actuator-duty derating rule above 40°C. Obtain a supplier curve or test the real cycle.

Evidence: S2S12S13S29

high confidence
Establish EU requirements for the supplied product and intended use.

A 12V-only unit is below LVD voltage scope, but that is not an exemption for a mains-powered assembly. Machinery classification and consumer-product scope require separate assessment; a voltage label does not decide the complete compliance route.

Evidence: S26S27S28S32

Mini and micro naming
Compare models, not labels

“12v mini linear actuator”, “12v mini actuator”, and “micro” are overlapping catalog descriptions, not standardized force or body-size classes. Check the selected model drawing and load curve (S1, S2, S13).

Moving force versus holding
250 N moving / 2500 N static

These are the published values for the LACT4-12V-10 example only. Static capacity is not a moving-load rating (S12).

Side load by stroke option
50 / 40 / 30 / 15 N

L12 maximum side load at full extension for the 10 / 30 / 50 / 100 mm stroke options. This is not a measured curve during travel (S13).

Unpowered holding
12 / 22 / 45 N

L12 back-drive force for 50:1 / 100:1 / 210:1 gearing. Speed or “mini” wording alone cannot establish holding ability (S13).

Published duty limits
20% L12/L16; 25% LACT4

Apply each model’s own load, ambient, cycle period and maximum run time. No universal high-temperature derating percentage is established here (S2, S12, S13, S29).

12V input ceiling example
13.5 V maximum for L12 12V

Nominal 12V wording does not establish tolerance of vehicle charging voltage or transients (S13, S17, S18).

Startup-current comparison
7 A versus 1.2 A average

LACT4 startup current and TB6612FNG average output rating illustrate a mismatch; peak duration, thermal limits and board design still need review (S12, S15).

Harness calculation example
1.10 V drop at 3.5 A

Calculated for a 4 m copper loop using Belden 83504 nominal DCR of 24 ohm/1000 ft. That cable lists only 1.6 A per conductor at 25°C; this is a loss illustration, not a cable recommendation (S31).

EU machinery application date
20 January 2027

Determine the supplied product classification and market-placement date before choosing conformity documents (S26).

LVD voltage scope
75–1500 V DC

A standalone 12V-only unit is below this voltage scope. Assess the supplied assembly separately; 12V alone does not establish SELV protection (S27, S32).

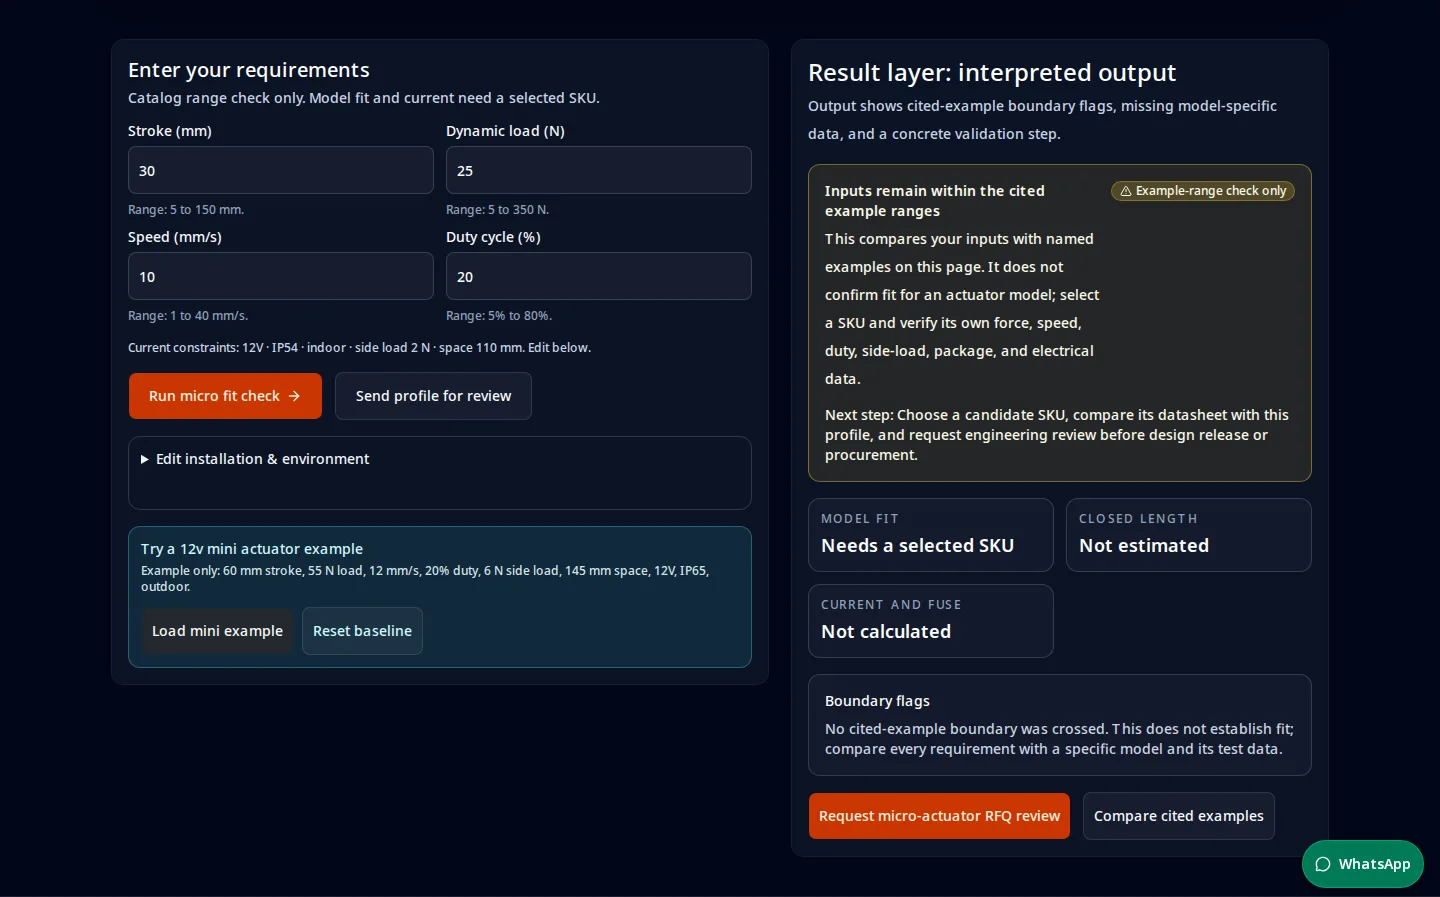
12V micro linear actuator fit checker showing a 30 mm stroke, 25 N load and model-fit limitations
Software execution recorded on 22 October 2026: 30 mm stroke, 25 N moving load, 10 mm/s, 20% duty, 2 N side load, 110 mm closed span, 12V, IP54, indoors. No cited-example boundary was crossed; model fit still needs a selected SKU. This screenshot documents the checker workflow, not measured actuator performance or a customer endorsement.

Who this page is for

Fit boundaries prevent over-trusting a fast tool result and make decision scope explicit.

Good fit
  • - You have a quantified stroke/load/speed request and can keep side load near zero with guided mechanics.
  • - You need a clear evidence trail to explain an early actuator choice to engineering or procurement.
  • - You can treat this as a screening layer before RFQ, not as final life certification.
Conditional fit
  • - Your request is near micro boundaries on force, duty, side load, or ingress target.
  • - You can run a short loaded bench test before freezing selection.
  • - You may need to shift from micro to mini class depending on package and reliability checks.
Not a fit
  • - You need high side-load tolerance, high duty-cycle operation, or harsh environment guarantees without validation.
  • - You are selecting by static-force or keyword wording only, without dynamic-load evidence.
  • - You cannot accept class migration to guided or industrial alternatives when micro limits are exceeded.

Method and evidence path

Method layer converts tool output into reproducible logic and reveals where confidence is strong or limited.

Fit and evidence flow map
SupplyFuse/OCPFit Engineload / duty / ingressActuator(s)Boundary decision path
Computation steps
StepFormulaWhy it matters
Normalize the request to engineering inputsnormalized_profile = {stroke_mm, dynamic_load_n, speed_mm_s, duty_pct, side_load_n, ingress_target}Keyword phrasing cannot size actuators. Converting request text into numeric and environmental inputs removes false certainty.
Compare values with cited example rangesreference_flags = compare(request, named_examples); no generic fit scoreThe examples use different models and configurations. Being inside their published ranges does not confirm fit for an unselected SKU.
Check electrical envelope for startupselect SKU -> use its load/current data -> validate supply, driver, wiring, and fuseWithout a specific model and its current curve, the checker cannot produce a defensible current or fuse estimate.
Check package and hold feasibilityselect SKU -> compare closed length, mounts, and back-drive data with the installationStroke alone does not determine closed length or unpowered holding; verify both against the exact model and linkage.
Route to next action by risk tieraction_path = f(example_boundary_flags, selected_model_data, validation_status)Results must end in executable action: proceed to RFQ, run targeted bench validation, or move to a larger guided family.

Regulatory and lifecycle boundary matrix

Clause-level boundaries are shown with direct decision impact. Where public data is insufficient, the page keeps uncertainty explicit.

BoundaryVerified ruleWhy it changes decisionsEvidence
Micro side-load toleranceReviewed P8/L16 datasheets publish stroke-dependent side-load limits in low ranges (2 N to 40 N in sampled rows).Side load is not a small correction term; it can completely re-route selection toward guided families.S1S2S5S6
Intermittent-duty assumptionsReviewed examples repeatedly publish 20% to 25% duty-cycle limits; one reviewed page explicitly describes 25% as one minute on in four.Do not approve repetitive automation duty on keyword confidence alone. Thermal profile is a hard gate.S1S2S3S12
Back-drive and unpowered holdingReviewed P8/L16 tables publish back-drive-force thresholds (10 N to 102 N sample range). Unpowered hold behavior depends on applied load and mechanism.Vertical axes and gravity-loaded linkages can drift unless back-drive margin is explicitly validated.S1S2S12
Startup inrush versus run currentReviewed 12V sample spec separates no-load, loaded, and startup/stall current (for example 1.2 A, 3.2 A, and 7 A).Fuse and supply sizing based only on average current can cause startup brownout or nuisance trips.S1S2S12
Nominal 12V versus component input ceilingA reviewed 12V micro family publishes 13.5 V as maximum input for the 12V option, so the nominal-voltage label does not guarantee unlimited input headroom.Vehicle and battery-charging contexts can invalidate assumptions quickly if input ceiling and protection path are not explicitly checked.S13S17S18
Controller-envelope mismatchReviewed controller datasheets publish hard current/voltage envelopes (TB6612FNG current limits and L298 total-drop behavior), which can be below startup needs in actuator examples.A mechanically valid actuator can still fail electrically if driver envelope and voltage headroom are not checked as first-class gates.S12S14S15
Road-vehicle transient and fuse frameworkISO 16750-2:2023 scopes electrical-load evaluation for road-vehicle E/E equipment, ISO 7637-2:2011 specifies conducted-transient test methods, and ISO 8820 parts define fuse-link test context.Bench-only pass conditions do not prove vehicle readiness; transient and fuse-path checks are part of release readiness.S17S18S19S20
Ingress scopeIEC 60529 publication metadata identifies edition 2.2 scope for enclosure IP classification, ISO 20653:2023 is road-vehicle scoped, and NEMA 250-2020 scope excludes conditions like condensation/corrosion/icing inside enclosures.An actuator IP class is useful but not a full-system or chemistry-proof approval signal.S7S8S9
US installation label boundaryNEMA enclosure FAQ states IP and NEMA types are not equivalent one-to-one and cites NEC 110.28 language that IP ratings are not substitutes for enclosure Type ratings.For U.S. installs, procurement and compliance notes need both technical ingress intent and the correct enclosure-type labeling path.S16
Installed-system rating inheritanceNEMA references state the installed system rating is constrained by the weakest component/least severe rating in the enclosure chain.A high-IP actuator does not preserve the same class if glands, fittings, or enclosure interfaces are lower-rated in the final build.S16S21
Fuse-link intent boundaryISO 8820-2:2014 states fuse-links are intended for cable protection, while component protection use requires explicit customer-supplier agreement.Without clear protection intent, teams can pass nominal current checks but still miss component-level survivability and branch-selectivity requirements.S19S22
Arc-flash and chemical-load boundaryNEMA FAQ states NEMA 250 does not address arc-flash hazard. ISO 16750-5:2023 notes continuous chemical-contact conditions may require other standards or explicit agreement.Ingress labeling alone is insufficient when programs include arc-flash policy or aggressive cleaning chemistry.S16S23
Dynamic vs static force interpretationReviewed listings separate dynamic and static force values on the same family, with sampled spreads from 1.25x to 10x.Moving-load sizing should use dynamic force. Static numbers are for hold/back-drive context.S2S4S12
Custom option procurement thresholdActuonix documentation states many custom options usually require MOQ 500; guided industrial options can also move into long lead-time quote tracks.If custom options are mandatory, procurement feasibility can dominate before mechanical optimization is complete.S1S11
Vibration and Mechanical Shock (ISO 16750-3)ISO 16750-3 scopes mechanical loads including vibration and shock for road-vehicle equipment.Brushed micro-actuators with small internal gearing are highly sensitive to chassis-transmitted vibration; bench electrical tests will not catch vibration-induced wear or contact loss.S25
Electromagnetic Compatibility (EMC / CISPR 25)CISPR 25 defines EMC limits for vehicles. Commutator arcing in brushed DC motors creates broadband EMI.Without proper internal LC filtering or shielded housing, a simple 12V motor can fail system-level radio disturbance tests, blocking release.S24
Harness resistance and voltage-drop budgetASTM B258 concerns AWG wire dimensions and properties, not an actuator cable-selection rule. Calculate voltage drop = I × 2L × r using one-way length L and the selected cable’s resistance per meter r.Worked example: 3.5 A × 4 m × (24 ohm / 304.8 m) = 1.10 V, or 9.2% of 12V. Belden 83504 is rated only 1.6 A per conductor at 25°C, so it is not a proposed 3.5 A harness. Verify ampacity and hot resistance separately.S30S31
EU machinery classification and timingRegulation (EU) 2023/1230 generally applies from 20 January 2027. Determine whether the supplied unit is a component, partly completed machinery or complete machinery.If classified as partly completed machinery under the applicable regime, obtain the required incorporation declaration and assembly instructions. Do not infer classification from “standalone actuator” wording.S26
LVD voltage scope and SELVLVD scope is 50–1000 V AC or 75–1500 V DC. A 12V-only unit is below those voltage limits; SELV also requires protective separation and fault-condition limits.Assess the complete supplied assembly, including any mains supply. Determine EMC, RoHS and other applicable requirements from product scope; low voltage alone is not a conformity route.S27S32
PWM interface and current recirculationThe L12 datasheet separates logic-level position inputs from motor-power wiring. ST’s L298 application circuit uses a bridge of fast recovery diodes for bidirectional motor control.Follow the selected driver and actuator circuit. A single ordinary flyback diode across a reversing motor becomes forward-biased in one direction. Validate stopping and transient energy; no generic TVS part or 100% duty setting is approved here.S13S14S15
Insulation thermal classification versus actuator dutyIEC 60085 covers insulation thermal endurance and class assignment. Its public scope does not establish a universal actuator duty-versus-ambient curve.Do not assume halving duty makes an actuator safe above 40°C or outside its rated ambient range. Obtain a model-specific curve and validate winding, housing and driver temperatures at the real load and cycle period.S2S13S29
Radial side load and cantilever bending boundaryLINAK LA14 prohibits side loading; Thomson warns that off-axis loads can cause binding and damage. For illustration, a 20 N transverse force with a 0.15 m perpendicular lever arm gives M = F × L = 3.0 N·m. This calculation does not establish an allowable moment or a failure threshold.Use the selected model’s side-load rating at its stroke. Route transverse loads and moments through adequately rated guides; pivoting mounts help alignment but do not replace guide capacity or prove zero side load.S33S35
12V mini actuator wiring loss: model and cable data requiredPA-14 lists 5 A full-load current at 12V; this is not its startup/stall rating. For a loss illustration only, 3.5 A × 4 m × (24 ohm / 304.8 m) = 1.10 V using Belden 83504 nominal DCR. That cable is rated only 1.6 A per conductor at 25°C and is unsuitable for the illustrated current.There is no universal 18/16 AWG or 3% rule established here. Select a cable using actual one-way length, running/startup current, hot conductor resistance, ampacity, connector ratings and minimum motor voltage. Voltage drop alone does not quantify torque loss or predict a stall.S30S31S34
Model-specific duty cycle and continuous run timeL12/L16 list 20% maximum duty; the PA-14 example lists 25% with a 5-minute-on / 15-minute-off period. A percentage alone does not establish maximum continuous run time or an IEC motor-duty classification for every mini actuator.Confirm load, ambient temperature, cycle period and maximum run time for the exact SKU. Do not substitute many short cycles for a published period without validation. If the requirement exceeds its rating, request a supplier-approved alternative or a continuous-duty model.S2S13S34

Benchmarks and profile examples

These rows show reproducible profile dimensions. They are decision guides, not universal guarantees.

ProfileFamilyRun current (A)Peak current (A)Duty signalDecision
Micro rod baseline (Actuonix P8 class)P8 12V datasheet envelopeN/A (stall listed: 0.45 A @12V)0.45 A stall @12V20%Use for very small inline loads; published side-load limits are low (2 N to 5 N by stroke).
Micro rod extended stroke (Actuonix L16 class)L16 12V datasheet envelopeN/A (load curves provided)0.65 A stall @12V20%Check back-drive and side-load limits early; published back-drive values span 31 N to 102 N by gear ratio.
Mini rod fallback (PA-01 page snapshot)PA-01 12V pageN/A (not publicly listed on reviewed page)N/A25% (5 min on / 15 min off)Use when micro force or ingress gates fail, but request missing current curves before final electrical design.
Micro axial profile with explicit input ceiling (Actuonix L12)L12 12V datasheet envelopeN/A (load curves provided)0.246 A stall @12V option20%Adds an explicit input ceiling signal (13.5 V max input for the 12V option), so power-path headroom must be verified before release.
Light-duty reference with explicit inrush (Pololu LACT4)Pololu 12V light-duty sample SKU1.2 A no-load / 3.2 A max-load7 A startup inrush (stall spec)25% (or 1 min in 4)Shows why startup current should be a first-class power-sizing input, not an afterthought.
Low-cost dual H-bridge driver envelope (TB6612FNG)TB6612FNG dual DC motor driver datasheet1.2 A average per channel3.2 A single pulse (10 ms)2 A pulse allowed only at duty <= 20% (20 ms)Treat as a controller-envelope gate: startup current above these values requires architecture change or higher-current path.
Guided industrial migration pathGuided actuator architecture (Thomson/Tolomatic class)N/A (model-specific)N/A (model-specific)Model-specificUse when side-load path or lifecycle obligations exceed bare-rod micro assumptions.

Electrical envelope and unknowns

This section separates published electrical/environment signals from unresolved data so teams can avoid forcing conclusions when public evidence is incomplete.

ProfilePublished signalsUnknowns / pending confirmationDecision impactEvidence
Actuonix P8 micro (12V)Max side load 2 N to 5 N by stroke, back-drive force 10/40/65 N, duty 20%, operating range -10°C to +50°C, IP54, max static force 180 N.Continuous current by load point is not explicitly published in the reviewed P8 datasheet.If vertical load hold is required, confirm back-drive margin and add brake or mechanical lock when required.S1
Actuonix L16 micro (12V)Max side load 40/30/20 N by stroke, back-drive force 31/46/102 N, duty 20%, stall current 0.65 A, operating range -10°C to +50°C, IP54.Datasheet explicitly says life should be validated in each application and environment.Do not treat "holds when unpowered" as unconditional; verify gravity and linkage forces against back-drive values.S2
PA-01 mini fallback (12V page)Force options up to 225 lb, duty 25% (5 min on / 15 min off), IP65, operating range 5°C to 40°C on reviewed page.Reviewed page does not publish run or startup current values for the same snapshot.When migrating from micro to mini, require electrical-current data before freezing controller and fuse sizing.S3
Actuonix L12 micro (12V option)Max input voltage 13.5 V for 12V option, stall current 246 mA, duty 20%, operating range -10°C to +50°C, IP54, side-load limits 50/40/30/15 N by stroke, and back-drive force 12/22/45 N.Datasheet does not provide universal lifetime predictions for every duty/load waveform.Treat voltage headroom and transient behavior as explicit design gates; do not assume all nominal 12V buses stay within component input limits.S13
Pololu LACT4 12V sample SKUCurrent is listed as 1.2 A no-load, 3.2 A at max load, 7 A startup inrush; dynamic force 250 N and static force 2500 N; duty 25%; -25°C to +65°C; IP65.Single SKU data point; should not be generalized to every micro/mini actuator family.Power path and protection should be sized for startup inrush and dynamic load, not static force or average current alone.S12
Controller-envelope boundary (TB6612FNG / L298)TB6612FNG publishes 1.2 A average and 3.2 A peak output current envelope (with operating VM up to 13.5 V). ST L298 publishes total DC current up to 4 A and shows total driver drop data (for example 1.80 V typ at IL=1 A, 4.9 V at IL=2 A in datasheet test conditions).Thermal and duty derating are board- and cooling-dependent; module-level implementation quality varies by vendor board.Add controller selection to the same checklist as actuator selection. Startup current and voltage headroom must clear both actuator and driver limits.S14S15
Road-vehicle electrical test and fuse boundaryISO 16750-2:2023 scopes electrical loads for road-vehicle E/E equipment; ISO 7637-2:2011 (confirmed in 2025) defines conducted transient compatibility test methods for 12V/24V systems; ISO 8820 parts define fuse-link test frameworks and ratings.Full clause-level acceptance details are paywalled and require licensed standards for contractual claims.For vehicle programs, bench fit checks should be paired with transient-immunity and fuse-path validation before release sign-off.S17S18S19S20
Standards and rating scope boundaryIEC 60529 (ed. 2.2) covers enclosure IP classification, ISO 20653:2023 applies to road-vehicle electrical equipment, and NEMA 250-2020 scope excludes conditions like condensation/corrosion/icing inside enclosures.Clause-by-clause acceptance details require licensed full-text standards access.Choose the right standard family by market context and validate full installation details (cable entry, connector, chemistry) at quote stage.S7S8S9
Installed-system ingress inheritance boundaryNEMA FAQ and NEMA Bulletin No. 123 both state installed assembly protection follows the weakest component or least severe rating in the chain.Catalog IP/NEMA labels alone do not prove that each cable entry, fitting, enclosure, and connector in the final installation shares the same tested level.Treat ingress as a chain verification task, not a single-part label check. Add an installation-level rating matrix before release.S16S21
Fuse-link intent and selectivity boundaryISO 8820-2:2014 says automotive fuse-links are intended for cable protection, and component protection use needs explicit customer-supplier agreement.Part-level purchase pages do not publish full branch selectivity, nuisance-trip, and downstream component-survivability behavior for every harness topology.Document whether the branch goal is harness protection only or component protection too, then validate with the actual fuse family and harness impedance.S19S20S22
Road-vehicle chemical-load applicability boundaryISO 16750-5:2023 defines chemical-load test scope for road-vehicle E/E equipment and notes continuous-contact conditions may require other standards or explicit agreement.Chemical compatibility across cleaners, de-icing fluids, and long-duration exposure is not guaranteed by ingress class alone.If vehicle cleaning/chemical exposure is expected, add a chemical-load validation plan in addition to ingress and electrical checks.S23
Vehicle EMC / EMI boundary (CISPR 25)CISPR 25 defines limits for radio disturbance characteristics to protect on-board receivers from electrical noise.Motor suppression and harness emission data are not established for every candidate. Request evidence rather than inferring filtering or shielding from a generic housing.Specify EMI suppression at the motor source and evaluate harness routing if used near vehicle communications or GPS.S24

Control-path constraints before release

Actuator fit is only half of the decision. Controller-envelope and protection-path checks decide whether startup events remain stable in real deployments.

OptionPublished envelopeWhere it fitsHard limitEvidence
TB6612FNG low-current dual H-bridgeVM up to 15 V absolute max; operating VM up to 13.5 V; output 1.2 A average and 3.2 A peak.Useful for truly small loads with controlled startup envelope and good thermal layout.Startup current above peak envelope or repeated high-duty pulses can exceed the driver class quickly.S15
L298 bipolar dual bridgeOperating supply up to 46 V, total dc current up to 4 A, with published total-drop data in datasheet electrical characteristics.Can be viable where higher supply headroom is available and efficiency loss is acceptable.Voltage drop and thermal behavior can consume actuator headroom at low-voltage operation.S14
DPDT relay/reversing path with fuse-link strategyActuonix L12 datasheet explicitly allows polarity reversal via DPDT switch/relay or H-bridge; ISO 8820 parts define fuse-link frameworks.Practical fallback when actuator startup envelope exceeds low-current driver-board limits.Still requires transient and fuse validation in the real harness/application context.S13S19S20

Actuator class comparison

Comparison layer focuses on trade-offs, failure points, and validation gates instead of feature checklists.

OptionWhere it winsWhere it breaksValidation gateBest for
Compact rod actuator: L12 / P8 examples (S1, S13)Small packages and multiple gearing, stroke and control options; use dimensioned drawings.Moving force, side load, holding and duty remain model-specific; compactness is not a shock or life rating.Check the same SKU’s loaded-speed curve, extended side-load rating, closed length and back-drive force.Small inline mechanisms after load and mounting validation.
Larger compact actuator: LACT4-12V-10 example (S12)Published 250 N moving force, 2500 N static force and 25% duty for this specific example.7 A startup current and a larger installation envelope can exceed a small controller or enclosure.Check the exact drawing, startup waveform, harness voltage drop and driver pulse capacity.Compact mechanisms whose requirements exceed a smaller candidate’s verified limits.
12V mini linear actuator: PA-14 example (S34)The PA-14 12V product table lists 35 / 50 / 150 lbf moving-load options (about 156 / 222 / 667 N), with separate loaded speeds. Its dimensioned drawing determines installation space.Published 5 A full-load current and 25% duty (5 minutes on / 15 minutes off) may exceed a smaller controller or cycling requirement. Startup current and side-load allowance need separate confirmation.Check the exact SKU’s load-speed curve, drawing, startup waveform, cable ampacity and voltage drop. Full-load current is not a peak-current rating; verify mounting and power-off holding separately.Compact axial positioning after model-specific mechanical, electrical and thermal checks.
Guided electric actuator / linear slideAn external rail or bearing can carry side loads and moments independently of the rod.Guide, bracket and alignment work add cost and installation space.Define bearing loads, moments and cycle profile with the supplier.Offset loads and cantilevered mechanisms requiring a dedicated guide.
Industrial actuator familyA candidate path when compact examples cannot meet required load, duty or environment.Size, current, cost and ingress capability vary by model; no generic force or IP rating is implied.Obtain the candidate’s load-speed, duty-temperature and mounting data before selection.Applications beyond the cited compact examples, subject to engineering review.
Custom electric cylinder programA possible path for nonstandard stroke, connector, enclosure or control requirements.MOQ, tooling cost, qualification and delivery require a written quote; P8 custom guidance is not a universal MOQ (S1).Freeze requirements and request written prototype, test and production terms.Programs where standard candidate models cannot meet documented requirements.

Radial side load and cantilever moment

A transverse force creates a bending moment about its support (M = F_side × perpendicular lever arm). Compare the selected model’s side-load rating at the actual stroke; this diagram establishes no allowable moment or failure threshold. Route unsupported loads through rated guides and check pivot alignment (S13, S33, S35).

Actuator Body(Internal Acme / Motor)Perpendicular lever arm (L)Axial Thrust F_axialWithin model-specific limitsRadial Side Load F_sideCheck the selected model’s ratingCantilever Bending Moment:M = F_side × LRisk: Bushing wear, friction binding, stallMounting review (S13, S33, S35):Use rated guides for transverse loads; pivots aid alignment.

Risk and mitigation map

Risk layer covers misuse risk, cost risk, and scenario mismatch risk with concrete mitigation actions.

Risk matrix (impact vs probability)
ProbabilityImpactLowMediumHigh
Using static force as moving-force proof
Impact: Field stalls, overheated motors, and early wear

Warning sign: Spec sheet row selected by highest force number only

Mitigation: Keep dynamic-force row as the primary gate and validate startup current under load.

Ignoring side-load path
Impact: Binding, bent rod, and shortened service life

Warning sign: Offset linkage with no guidance or anti-rotation plan

Mitigation: Add guidance or re-route to a guided actuator family before RFQ.

Assuming unpowered self-locking without back-drive check
Impact: Drift or drop events when power is removed

Warning sign: Vertical axis has no brake or hard stop and no back-drive margin calculation

Mitigation: Compare worst-case external load with published back-drive-force data and add lock/brake if margin is insufficient.

Sizing power by average current only
Impact: Startup brownouts, nuisance fuse trips, and controller resets

Warning sign: Supply is selected from no-load current while startup/stall current is not reviewed

Mitigation: Size wiring, protection, and supply for startup inrush and verify with current capture during loaded starts.

Controller class selected below startup envelope
Impact: Bridge overheating, repeated trips, or no-start behavior in field

Warning sign: Actuator startup current is not compared against controller peak/current-drop constraints

Mitigation: Validate startup current and voltage headroom end-to-end; migrate to higher-current or relay-based architecture when needed.

Assuming nominal 12V always stays inside component limits
Impact: Input-stage overstress and reduced reliability margin

Warning sign: Only nominal voltage is documented while component max input and transient standards are omitted

Mitigation: Document component input ceiling, add surge/transient checks, and align test scope with road-vehicle standards where applicable.

Selecting power wiring without current and resistance data
Impact: Excessive voltage drop or conductor heating, depending on current, length and installation

Warning sign: Selecting lead wire gauge based on AC line intuition or signal ribbon cables

Mitigation: Calculate loop drop at startup and running current using the chosen cable data, then verify ampacity, ambient, connectors and fuse coordination (S30, S31).

Accepting conformity documents without checking supplied-product scope
Impact: Incorrect conformity mapping and late documentation or product redesign

Warning sign: The declaration does not distinguish a 12V-only unit from an assembly with a mains supply

Mitigation: Have the supplier document product classification, intended use, placement date and applicable legislation. Request incorporation documents only when that classification applies (S26–S28).

Driving PWM into mechanical limit switches without snubber protection
Impact: Driver MOSFET avalanche punch-through and premature contact pitting

Warning sign: Speed control is active right up to hard mechanical travel limits

Mitigation: Use the driver manufacturer’s bidirectional recirculation circuit and validated stop logic. Do not put a single flyback diode across a reversing motor or treat 100% duty as transient protection (S14).

Inferring unpowered holding from actuator size or speed
Impact: Axis back-driving or creep under unpowered payload or mechanical vibration

Warning sign: Selecting high-speed low-reduction models for vertical or cantilevered loads

Mitigation: Verify backdrive hold rating; specify high-reduction gear ratio or external electromechanical brake for vertical holding.

Using IP label alone in U.S. enclosure decisions
Impact: Compliance relabeling rework and delayed release

Warning sign: Installation notes include only IP code with no enclosure Type path for U.S. projects

Mitigation: Include enclosure Type and applicable code path in procurement/QA docs; treat IP as ingress signal, not legal substitution.

Assuming one high-IP part guarantees the full installed assembly rating
Impact: Unexpected field ingress failure and late redesign of glands/fittings

Warning sign: Only actuator rating is documented while cable entry, fitting, and enclosure ratings are not tracked as a chain

Mitigation: Create an installed-rating matrix and enforce weakest-link review before sign-off.

Treating automotive fuse choice as component protection by default
Impact: Harness may be protected while sensitive controller/actuator electronics still fail

Warning sign: Fuse is selected only by nominal current without explicit statement of cable-vs-component protection intent

Mitigation: Declare protection intent in requirements, then validate fuse behavior with the actual branch impedance and load profile.

Over-trusting ingress labels
Impact: Corrosion, connector failure, and enclosure leakage in service

Warning sign: IP rating is treated as complete environmental approval

Mitigation: Define cable, connector, washdown chemistry, and enclosure boundary in quote requirements.

Assuming ingress class covers arc-flash and chemical-lifecycle exposure
Impact: Safety and durability gaps discovered late in validation

Warning sign: Specification closes on IP/NEMA class only, without arc-flash policy checks or chemical-contact test scope

Mitigation: Track arc-flash and chemical-load requirements as separate gates and assign standards ownership before procurement freeze.

Duty-cycle underestimation
Impact: Thermal drift and premature life loss in repetitive cycles

Warning sign: Application duty is continuous or near-continuous but model is intermittent-duty class

Mitigation: Run cycle-duty measurement and move to higher-duty family when required.

Packaging decision made from stroke only
Impact: Late-stage enclosure collision and bracket redesign

Warning sign: No closed-length or mount geometry check in design review

Mitigation: Use the selected model’s dimensioned drawing, mounting clearances and tolerances before freezing CAD.

Late discovery of custom MOQ and lead time
Impact: Program delays and procurement rework

Warning sign: Custom connector/stroke requested without supply-path check

Mitigation: Confirm MOQ and delivery path at concept stage for custom requirements.

Assuming brushed DC micro actuators pass vehicle EMC out-of-the-box
Impact: Interference with GPS/CAN/Radio and compliance failure

Warning sign: No filtering capacitors/inductors specified on the motor leads

Mitigation: Require CISPR 25 test reports or mandate internal motor filtering for vehicle applications.

Ignoring chassis vibration profiles in actuator selection
Impact: Premature gear wear and lost electrical contact at brushes

Warning sign: Actuator is only verified for static loads and lacks ISO 16750-3 vibration test alignment

Mitigation: Align structural mounting and request vibration/shock test data matching the specific vehicle installation zone.

Cantilever side-loading on extended 12v mini linear actuator shaft
Impact: Binding, wear or actuator damage from off-axis loading

Warning sign: Linkage path swings through an arc without a clevis pivot, or moving mechanism lacks linear guide rails

Mitigation: Size guides for the actual transverse loads and moments, align mounting pivots, and check the candidate’s side-load limits. A rail family name alone does not establish capacity (S13, S33, S35).

Excessive harness loss or insufficient current capacity
Impact: Low motor voltage, overheating, reduced performance or supply resets

Warning sign: Cable selected by gauge alone without resistance, ampacity or loaded-start measurements

Mitigation: Calculate loop loss, check hot ampacity and connectors, coordinate protection, and measure supply and motor-terminal voltage during loaded starts. Confirm startup current separately from full-load current (S31, S34).

Unverified power-off holding under load or vibration
Impact: Unintended drift or collapse of held mechanism (e.g., hatch, flap, damper) when 12V power is removed

Warning sign: Power-off holding inferred from speed, screw type or dynamic force instead of the selected model’s holding data

Mitigation: Verify published back-drive force for the selected gearing and validate the worst-case load and vibration. Use a rated mechanical lock or fail-safe brake where movement is unacceptable; short-circuit motor braking does not establish static power-off holding (S13).

Scenario cards

Illustrative decision paths only: outcomes are not measured test results and recommendations require model-specific validation.

Compact lab fixture axis

Assumptions: Stroke 30 mm, dynamic load 20 N, side load ~0 N, intermittent duty, indoor use

Screening note: The sample-range screen has no triggered flags for these assumptions; model fit, closed length, and electrical margin remain unconfirmed.

Recommendation: Proceed with micro RFQ and keep side-load guidance in the mechanical drawing.

Vertical hatch with power-off hold requirement

Assumptions: Stroke 60 mm, gravity-loaded linkage, actuator must hold when unpowered

Screening note: Power-off holding remains unresolved until the selected gearing’s back-drive rating is compared with the linkage load; no physical test is reported.

Recommendation: Add mechanical lock/brake or re-select a family with verified hold strategy for the full load orientation.

Controller brownout during startup

Assumptions: 12V supply sized near average running current with long cable run and shared loads

Screening note: A supply sized only for running current may sag during startup. Capture current and motor-terminal voltage to determine whether that risk occurs in the actual assembly.

Recommendation: Re-size supply/fuse/wiring for startup current, then confirm with captured current and voltage traces.

Outdoor access flap project

Assumptions: Stroke 80 mm, dynamic load 70 N, periodic splash exposure, duty bursts throughout shift

Screening note: Outdoor exposure and repeated cycles require the candidate’s installed-ingress and duty-temperature evidence; these assumptions alone cannot establish fit.

Recommendation: Validate enclosure and cycle profile, or move to mini IP65/IP67-capable family.

IP67 actuator but downgraded installation chain

Assumptions: Actuator is selected at IP67, but cable gland and field enclosure are not verified at equivalent installed rating

Screening note: An unverified cable entry or enclosure leaves the installed protection level unresolved, even when the actuator alone carries an IP67 rating.

Recommendation: Audit fittings, cable entry, and enclosure as one chain and sign off with the lowest-rated component rule.

Custom connector and stroke request

Assumptions: Need non-standard stroke and connector pinout for low-volume pilot

Screening note: Mechanical fit and supply terms remain unconfirmed until the supplier reviews the drawing and quotes the custom variant.

Recommendation: Confirm MOQ/lead-time before committing micro family and timeline promises.

Commercial vehicle hidden air flap / grille shutter

Assumptions: Stroke 50 mm, dynamic load 140 N, 12V battery power, -20°C to +70°C, 3m wire run, subject to engine compartment heat and road shock

Screening note: Illustrative risk: aerodynamic loads, hot ambient, vibration and harness resistance may exceed an unverified compact model’s limits; no measured failure is claimed.

Recommendation: Request load-speed and duty-temperature data for the actual environment, calculate harness drop at the candidate’s current, and agree vibration tests before selection.

Mobile medical cart display height & tilt mechanism

Assumptions: Stroke 80 mm, dynamic load 80 N, quiet indoor operation (<45 dBA), unpowered position locking required

Screening note: Illustrative risk: insufficient power-off holding or objectionable noise may rule out a candidate. This is a hypothetical scenario, not a clinical case report.

Recommendation: Specify the required holding force, noise measurement conditions and approved control interface. If the finished product is a medical device, assess its product-specific obligations; this page does not establish its compliance route.

Automotive active aerodynamic louvers & tailgate flap (12V mini linear actuator)

Assumptions: Stroke 150 mm, dynamic load 350 N, 12V DC vehicle battery, -30°C to +85°C ambient, 2.5m harness, subject to road shock and high-pressure spray

Screening note: The requested temperature range exceeds the reviewed L12 range, and the 150 mm stroke exceeds its published options. Gear failure, cable gauge and ingress suitability cannot be inferred from these assumptions (S13).

Recommendation: Request a candidate with documented load-speed, temperature, holding and mounting ratings. Calculate cable drop and ampacity from its current; agree ingress and vibration tests, guide transverse loads, and follow the approved driver protection circuit (S13, S14, S25, S31).

Evidence gaps and minimum executable path

Unknowns are explicit. No synthetic certainty is added where public evidence is insufficient.

Claim areaCurrent stateStatusMinimum executable path
Exact life prediction for each custom motion profilePublic catalogs provide family-level limits but not universal cycle-life guarantees for every custom duty and load waveform; no reliable open dataset provides a universal curve.pendingRun project-specific life and thermal validation before final warranty claims.
Temperature-duty derating across mixed familiesReviewed pages publish different operating-temperature windows, but no unified derating curve across micro and mini families; reliable public cross-family derating data remains unavailable.pendingRun duty/temperature validation on the exact candidate SKU and use measured current/temperature rise as the release gate.
Mechanical limit switch endurance under inductive PWM choppingGeneric catalog datasheets specify contact amperage for resistive loads, but cycle endurance under inductive DC motor arcing during PWM speed modulation is not publicly characterized across commodity suppliers.partialAgree a load-matched endurance protocol and stop/reversal conditions with the supplier, use the approved driver protection circuit, and log contact resistance and transients. No universal cycle count or clamp is established.
Acoustic noise emissions (dBA) across PWM carrier frequenciesAudible motor squeal and gear whine vary widely depending on gear material (plastic vs brass vs powdered steel) and PWM drive frequency; standardized noise maps are missing from public catalog sheets.pendingAgree distance, background noise, load, mounting and approved control frequencies; measure noise and driver temperature on the candidate. A carrier above audible range does not guarantee quiet operation.
Clause-level acceptance details from paid standardsPublic metadata confirms scope and edition history for IEC 60529/ISO 20653, but full clause text is paywalled.partialObtain licensed standards copy (or certified test-lab interpretation) before compliance claims in contractual documents.
Universal side-load tolerance in unknown linkage geometriesPublished side-load numbers exist for selected examples only; linkage geometry can alter stress significantly.partialModel linkage forces and verify with instrumented bench testing at worst-case positions.
Chemical compatibility for every washdown environmentIP and enclosure references provide ingress scope, but chemistry and aging compatibility remain application-specific.pendingRequest seal/material compatibility confirmation and test with actual cleaning media.
Lead-time certainty across custom variantsPublic references show custom path constraints but cannot guarantee every supplier timeline at quote time.partialCollect written quote commitments for MOQ, lead time, and change-order limits.
Module-level thermal derating for third-party driver boardsController IC datasheets provide silicon-level limits, but board-level thermal/headroom behavior varies by PCB and cooling implementation; no universal open dataset covers all module vendors.pendingMeasure startup current and steady thermal rise on the exact controller module at worst-case duty/ambient before release.
Per-SKU certification evidence for installed enclosure chainsPublic standards and FAQs define boundaries, but open web evidence does not guarantee each purchased fitting/enclosure/connector set has matching installed certification in the final configuration.partialRequest listing files or test reports for each enclosure-chain component and verify the assembled configuration against project obligations.
Dynamic side-load cantilever fatigue limits for unguided mini linear actuators across stroke extensions (100–300 mm)The reviewed sources do not establish a shared fatigue curve or allowable bending moment across models. L12 gives stroke-specific extended side-load ratings; LINAK LA14 prohibits side loading (S13, S33).partialSize guides for the actual transverse loads and moments, align pivots and validate reactions throughout travel against the selected model’s limits. Neither a pivot nor a deflection measurement establishes zero side load.

12V mini and micro actuator questions

Compare size, load, wiring, holding and operating conditions before choosing a model.

Names, interfaces and model requirements
Compare catalog descriptions, motor interfaces, closed dimensions and loaded speed before choosing a compact actuator.
Is a "12v micro linear actuator" different from a "micro linear actuator 12v"?

Not from word order alone. "12v micro linear actuator", "12 volt micro linear actuator", and "micro linear actuator 12v" describe the same selection request; compare stroke, dynamic load, side-load, duty, package, and power requirements against the exact model datasheet.

Does a "12v dc mini linear actuator" accept motor PWM or a position signal?

Check the exact control option. A two-wire motor model uses polarity reversal through a suitable driver; an integrated position controller uses its specified command interface. Logic-level position PWM and motor-power PWM are different signals and cannot be interchanged (S2, S13).

Is a "12v actuator small" enough if I only know the available space?

Available space is only one input. Compare closed hole-to-hole length, required stroke, extended length, mounting clearance and the moving load. Do not infer closed dimensions by adding an assumed offset to stroke; use the selected model drawing (S2, S13).

What requirements should I collect before comparing "12v micro linear actuator" models?

Record stroke, dynamic force, loaded speed, duty cycle, side-load path, installation space, supply voltage, current demand, and environmental exposure. Then compare those values with each candidate SKU.

Which loaded speed should I compare for a 12V micro model?

For a catalog entry described as "12v linear actuator micro", compare speed at your moving load using the same gearing, voltage and control option. Maximum force and maximum no-load speed are different operating points; neither establishes that both can be delivered together (S2, S13).

How does a "12v mini actuator" relate to micro 12V models on this page?

A "12v mini actuator" and a micro 12V unit can describe the same compact product; these names do not define a standard size or force class. Use the mini example in the fit checker, then compare stroke, moving load, loaded speed, duty cycle and mounting dimensions with the exact candidate datasheet (S2, S13).

What is the mechanical difference between a "12v mini actuator" and a "12v micro linear actuator"?

“12v mini actuator” and “12v micro linear actuator” are overlapping supplier descriptions, not standardized mechanical classes. For example, the cited L16 offers a 140 mm stroke option, so a universal micro limit below 100 mm would be misleading. Compare dimensioned drawings, loaded-speed curves, current and holding ratings for the same candidate SKU (S2, S13).

Is a "12v mini linear actuator" different from a "micro linear actuator 12v"?

No standardized engineering boundary separates a "12v mini linear actuator" from a "micro linear actuator 12v". These are overlapping catalog descriptions. Use the checker to organize requirements, then verify stroke, loaded speed, moving force, closed length, duty and current against the exact candidate datasheet; the checker does not verify those combined requirements for a model (S1, S2, S13).

Can I size and screen a "12v mini linear actuator" on this page?

Use this page for an initial requirements check for a "12v mini linear actuator". Follow the preset anchor (#fit-check-12v-mini-linear-actuator), then press Load mini example to populate an illustrative profile. The result flags individual cited-example boundaries; it does not select a SKU, calculate duty headroom, estimate closed length, size current/fuses or certify fit. Send the profile and a candidate datasheet for engineering review.

What side load or radial force can a "12v mini linear actuator" tolerate before mechanical failure?

There is no universal radial-force or failure threshold for a "12v mini linear actuator". LINAK LA14 prohibits side loading, while L12 lists maximum extended side loads of 50 / 40 / 30 / 15 N for its 10 / 30 / 50 / 100 mm stroke options. These are model-specific ratings, not failure-test results. Use the exact candidate’s limits and route unsupported transverse loads and moments through adequately rated guides; pivot joints alone do not prove side-load capacity (S13, S33, S35).

Can 24 AWG wiring cause a 12v mini linear actuator to stall?

Excessive loop resistance can lower motor-terminal voltage, but gauge and the word “mini” do not establish a stall threshold. Calculate loss from the actual cable resistance, total out-and-back length and running/startup current; check ampacity and connectors separately. The Belden example here loses 1.10 V at an illustrative 3.5 A over a 4 m loop, but its 1.6 A conductor rating makes it unsuitable for that current. Do not infer a fixed torque-loss percentage or universal wire gauge from this example (S30, S31, S34).

How does leadscrew lead angle affect backdrive and holding ability in a 12v mini linear actuator?

Lead angle and friction affect backdriving, but screw type, speed or dynamic force alone cannot guarantee power-off holding. The L12 datasheet lists 12 / 22 / 45 N back-drive force for its 50:1 / 100:1 / 210:1 gear ratios. Use the exact model rating and validate load, wear and vibration; no universal lead-angle cutoff or holding multiple is established here. Where power-off movement is unacceptable, specify a validated mechanical restraint or fail-safe brake (S13).

Selection boundaries
These questions answer where micro selection works and where it should shift class.
What usually disqualifies a request from true micro class?

Most disqualifications come from dynamic load, side load, duty profile, startup-current limits, and environmental scope, not from keyword wording. When those signals rise, mini or guided families are usually safer.

Can I use static-force numbers to pick a moving-load actuator?

Use static numbers only as a secondary hold/back-drive context. Moving-load selection should be based on dynamic force and verified startup behavior.

Does "holds position when unpowered" mean guaranteed self-locking?

No. Reviewed datasheets also publish back-drive-force thresholds. If your external load exceeds that threshold, the axis can drift unless you add a brake or mechanical lock.

What wire gauge (AWG) should be used to wire a 12v mini actuator across a 2-meter to 5-meter run?

There is no universal gauge for a stated length alone. Use voltage drop = I × 2L × r with one-way cable length L, actual startup/running current I and the chosen conductor resistance r. At an illustrative 3.5 A, a 4 m loop with 24 ohm/1000 ft DCR loses about 1.10 V. That example cable is rated only 1.6 A per conductor at 25°C and is not a proposed power harness. Select a cable using ampacity, hot resistance, allowable motor voltage, connectors and fuse coordination (S30, S31).

Can I control the speed of a 12v mini actuator with PWM without damaging the internal limit switches?

Only use the control method approved for the selected actuator variant. Logic-level position PWM is different from chopping motor supply power. Follow the H-bridge manufacturer’s recirculation circuit and validate switch opening, braking and reversal under load. A single ordinary flyback diode across a reversing motor can short one commanded polarity; a generic TVS part or 100% duty near an end stop is not a validated substitute (S13–S15).

Under what conditions will a 12v mini actuator backdrive when unpowered?

It depends on the actual gearing, screw, load and mounting. There is no universal speed threshold or holding multiple. The L12 datasheet lists 12 / 22 / 45 N back-drive force for its three gear ratios, while the cited LACT4 listing says it holds position unpowered. Verify the candidate’s rating against worst-case load and vibration; use a validated restraint where power-off movement is unacceptable (S12, S13, S25).

Environment and reliability
These questions cover ingress, duty, and life-claim boundaries.
Does an IP rating on the actuator guarantee the full installation is protected?

No. IP class is an enclosure-level signal. Cable entries, connectors, chemistry, orientation, and cleaning method still need project-level validation. NEMA 250 scope language also lists exclusions that many teams miss.

If my actuator is IP67 but one cable fitting is lower, what rating should I assume for the assembly?

Assume the lower rating until proven otherwise. NEMA references state the installed system is constrained by the weakest component/least severe rating in the chain.

Should I apply IEC 60529 or ISO 20653 to my project?

Use IEC 60529 for general enclosure IP classification. Use ISO 20653 when your requirement is road-vehicle electrical equipment context. Do not mix them without documenting why.

Are micro 12V products usually continuous duty?

Not by default. Reviewed public examples in this cluster commonly publish intermittent-duty assumptions around 20-25%. Higher-duty use needs explicit validation or class migration.

How does ambient temperature above 40°C affect the 20% to 25% duty cycle rating of a 12v mini actuator?

Use the model’s specified operating range and duty-temperature curve. The public IEC 60085 scope covers insulation thermal classification, not a mandatory 50% actuator-duty reduction above 40°C. Reducing duty does not authorize use beyond rated ambient temperature. If the supplier has no applicable curve, keep the result unconfirmed and test the real load, cycle period, run time and mounting with agreed temperature limits (S2, S13, S29).

Can this checker replace life testing?

No. It is a screening layer that prioritizes what to test next. Final reliability commitments should come from duty- and load-matched validation.

Procurement and next actions
These questions convert results into executable RFQ actions.
How should I size power supply and fuse after reading this page?

Use startup/stall current as a hard electrical gate, then check continuous current at load. A supply sized only from no-load current is a common failure pattern.

Why are 12V actuators excluded from the EU Low Voltage Directive (2014/35/EU), and what CE directives actually apply?

LVD voltage scope is 75–1500 V DC or 50–1000 V AC. A 12V-only unit falls below that scope, but a supplied mains-powered assembly needs separate assessment. SELV requires protective separation and fault-condition limits, not just a 12V label. Determine EMC, RoHS and other obligations from product scope. GPSR concerns consumer products, including reasonably foreseeable consumer use; it is not a universal industrial-product or CE certification route (S27, S28, S32).

How does the new EU Machinery Regulation (EU) 2023/1230 affect 12V linear actuator procurement starting in 2027?

The new regulation generally applies from 20 January 2027. Assess placement date, transitional provisions and supplied-product classification. Where a unit is partly completed machinery, incorporation documentation and assembly instructions are required under the applicable regime; do not automatically classify every standalone actuator as partly completed machinery (S26).

Do ISO 8820 fuse-links automatically guarantee actuator/controller component protection?

Not automatically. ISO 8820-2 guidance frames fuse-links as cable-protection devices by default; component-protection intent should be explicitly agreed and then validated on the real branch.

Can I use a low-cost H-bridge board by default for a "12v actuator small" build?

Not by default. Compare actuator startup current and voltage headroom against the specific driver datasheet envelope (for example TB6612FNG or L298 constraints). If margins are weak, move to a higher-current path or relay-based reversal architecture.

When should I switch from catalog micro to custom quoting?

Switch when non-standard stroke, connector, sealing, or life constraints become mandatory. Custom path constraints (MOQ and lead-time) should be checked before schedule commitments.

What if this actuator is going into a road-vehicle electrical system?

Treat checker output as screening only. Add road-vehicle electrical-load and transient validation scope (for example ISO 16750-2 and ISO 7637-2 context) and define fuse-link path requirements before production release.

What should I send with an RFQ after using this checker?

Send normalized inputs: stroke, dynamic load, speed, duty, side-load path, ingress target, ambient profile, and space envelope. This prevents keyword-only quoting errors.

What is the minimum safe path when result confidence is low?

Run a short loaded bench test with current capture, verify side-load geometry, and request supplier confirmation on ingress and duty scope before purchase.

Sources and traceability

Every core conclusion is tied to explicit sources with access date and context notes.

S1 · Actuonix
P8 Series Actuator Datasheet

Accessed on 2026-09-29 · Source date: P8 datasheet Rev. A (Jan 2023)

  • - Publishes side-load limits of 5/5/3/2/2 N across 10/25/50/75/100 mm stroke options and back-drive force values of 10/40/65 N.
  • - Publishes stall current 450 mA @12V, maximum static force 180 N, maximum duty cycle 20%, operating range -10°C to +50°C, IP54, and custom-option MOQ guidance (typically 500 pieces).
Open source
S2 · Actuonix
L16 Series Actuator Datasheet

Accessed on 2026-10-22 · Source date: Current L16 datasheet PDF reviewed 2026-04-22

  • - Publishes 50/100/140 mm stroke options with 118/168/208 mm closed lengths, side-load limits of 40/30/20 N, and back-drive force values of 31/46/102 N.
  • - Publishes maximum static force 250 N, maximum duty cycle 20%, stall current 650 mA @12V, operating range -10°C to +50°C, IP54, and an explicit note that effective life must be tested in each application.
Open source
S3 · Progressive Automations
PA-01 Mini Linear Actuator

Accessed on 2026-06-25 · Source date: Product page reviewed 2026-04-22

  • - Reviewed page lists force options up to 225 lb and duty cycle 25% (5 minutes on / 15 minutes off).
  • - Reviewed page lists IP65 and operating temperature range 5°C to 40°C.
Open source
S4 · FIRGELLI
Classic Rod Linear Actuators

Accessed on 2026-06-25 · Source date: Product page reviewed 2026-04-22

  • - Reviewed page lists a 1 inch stroke option with 5.5 inch retracted length in the same family table.
  • - Reviewed page separates dynamic force and static force values, supporting moving-load vs hold-load interpretation.
Open source
S5 · Thomson
What Is Side Loading and How Does It Affect My Actuator?

Accessed on 2026-06-25 · Source date: Support article (current page)

  • - Defines side loading as radial/off-axis force that is not inline with actuator thrust.
  • - Warns side loading can cause binding and damage, supporting guidance and alignment checks as mandatory selection gates.
Open source
S6 · Tolomatic
IMA Integrated Motor Rod-Style Actuator Manual

Accessed on 2026-06-25 · Source date: 2024 manual

  • - States loads should be guided and inline with the thrust rod because misalignment reduces expected life.
  • - Lists IP65 standard with optional IP67 as a family-level boundary signal for ingress planning.
Open source
S7 · IEC
IEC 60529 Consolidated Version (IEC 60529:1989+AMD1:1999+AMD2:2013 CSV)

Accessed on 2026-06-25 · Source date: IEC publication page: edition 2.2, published 2013-08-29, stability date 2027

  • - Publication page lists edition 2.2 and scope for classifying enclosure protection by IP code for electrical equipment up to rated voltage 72.5 kV.
  • - Publication history notes consolidated corrigenda and confirms current valid consolidated reference.
Open source
S8 · ISO
ISO 20653:2023 Road Vehicles - Degrees of Protection (IP Code)

Accessed on 2026-06-25 · Source date: Edition 3 published 2023-08 (ISO 20653:2013 shown as withdrawn)

  • - Abstract states scope is road-vehicle electrical equipment, including IP designations, requirements, and test confirmation.
  • - Lifecycle section shows ISO 20653:2013 withdrawn and replaced by ISO 20653:2023.
Open source
S9 · NEMA
ANSI/NEMA 250-2020 Enclosures for Electrical Equipment (Contents and Scope)

Accessed on 2026-06-25 · Source date: NEMA 250-2020 scope PDF (©2021)

  • - Section 1.1 scope states the standard does not cover conditions such as condensation, gas vapor ignition, thermal damage, icing, corrosion, or contamination occurring within enclosures.
  • - Scope language ties usage to manufacturer instructions and NEC context, supporting installation-level caveats.
Open source
S10 · NIST
NIST Guide to the SI, Appendix B.9 Conversion Factors

Accessed on 2026-06-25 · Source date: NIST web page (updated 2025-08-18)

  • - Lists exact or high-precision conversion factors used in this page, including 1 in = 25.4 mm and 1 lbf = 4.448 222 N.
  • - Supports deterministic normalization when supplier specs mix imperial and SI units.
Open source
S11 · Thomson
M-Track 2 Inch Guided Actuator Listing

Accessed on 2026-06-25 · Source date: Product listing reviewed 2026-04-22

  • - Reviewed listing provides a guided-platform architecture reference distinct from bare-rod micro products.
  • - Used as migration signal when side-load and lifecycle obligations exceed micro-rod assumptions.
Open source
S12 · Pololu
Glideforce LACT4-12V-10 Light-Duty Linear Actuator Specs

Accessed on 2026-10-22 · Source date: Specs page reviewed 2026-04-22

  • - Lists 12V current values: 1.2 A no-load, 3.2 A at max load, and 7 A startup inrush (stall current note).
  • - Lists dynamic force 250 N vs static force 2500 N, duty 25% (or one minute in four), operating range -25°C to +65°C, and IP65.
Open source
S13 · Actuonix
L12 Miniature Linear Motion Series Datasheet

Accessed on 2026-10-22 · Source date: Rev. F (Nov 2019) datasheet reviewed 2026-04-28

  • - Publishes for the 12V option: max input voltage 13.5 V, stall current 246 mA, max duty cycle 20%, IP54, and operating range -10°C to +50°C.
  • - Publishes stroke-dependent side-load limits (50/40/30/15 N), back-drive force values (12/22/45 N), and explicit guidance that application life must be tested for specific load/environment conditions.
Open source
S14 · STMicroelectronics
L298 Dual Full-Bridge Driver Datasheet (DS0218 Rev 5)

Accessed on 2026-10-22 · Source date: Datasheet Rev 5 (2023-10) reviewed 2026-04-28

  • - Publishes operating supply up to 46 V and total DC current up to 4 A with channel-level absolute-current constraints listed in datasheet tables.
  • - The bidirectional DC motor application circuit uses four fast recovery diodes as recirculation paths; follow the circuit and device conditions rather than adding a single diode across a reversing motor.
  • - Electrical characteristics include total-drop behavior (for example 1.80 V typ at IL=1 A and 4.9 V at IL=2 A in listed test conditions), which is relevant for low-voltage actuator headroom checks.
Open source
S15 · Toshiba
TB6612FNG Dual DC Motor Driver Datasheet

Accessed on 2026-10-22 · Source date: Datasheet page reviewed 2026-04-28

  • - Publishes output current envelope of 1.2 A average and 3.2 A peak, with VM absolute maximum 15 V and operating VM up to 13.5 V.
  • - Includes design cautions on inrush/back-EMF protection and recommends appropriate fuse/protection strategy for abnormal-current scenarios.
Open source
S16 · NEMA
NEMA FAQs: Enclosures

Accessed on 2026-06-25 · Source date: NEMA FAQ PDF reviewed 2026-05-14

  • - FAQ states it is not possible to treat IP degree and NEMA Type as one-to-one equivalent because scope and test dimensions differ.
  • - FAQ item 19 cites NEC 110.28 wording that IP ratings are not substitutes for enclosure Type ratings in U.S. electrical installations.
  • - FAQ notes overall installed Type rating is limited by the least severe component in the field-installed system chain.
  • - FAQ also states NEMA 250 does not address arc-flash hazards and references NFPA 70E / IEEE guidance for that topic.
Open source
S17 · ISO
ISO 16750-2:2023 Road Vehicles - Environmental Conditions and Testing (Electrical Loads)

Accessed on 2026-06-25 · Source date: Edition 5 published 2023-07

  • - Abstract scopes electrical loads for road-vehicle electrical/electronic systems and states loads can vary with harness impedance.
  • - Publication metadata confirms current edition and lifecycle history, supporting time-specific standards traceability.
Open source
S18 · ISO
ISO 7637-2:2011 Road Vehicles - Electrical Transient Conduction Along Supply Lines

Accessed on 2026-06-25 · Source date: Edition 3 (2011-03), confirmed 2025

  • - Abstract defines conducted-transient compatibility bench-test methods for equipment on 12 V and 24 V road-vehicle electrical systems.
  • - ISO lifecycle metadata shows the publication remains current after confirmation in 2025.
Open source
S19 · ISO
ISO 8820-1:2014 Road Vehicles - Fuse-links (Definitions and General Test Requirements)

Accessed on 2026-06-25 · Source date: Edition 4 published 2014-12

  • - Abstract defines terms and general test requirements for fuse-links in road-vehicle electrical DC systems.
  • - Scope note states the part is used with other ISO 8820 parts and is not applicable to fuse holders.
Open source
S20 · ISO
ISO 8820-10:2020 Road Vehicles - Fuse-links Type L (High Current Miniature)

Accessed on 2026-06-25 · Source date: Edition 2 published 2020-12

  • - Abstract specifies Type L fuse-link ratings and tests, including 32 V rated voltage context, current rating <= 60 A, and 1,000 A breaking-capacity reference.
  • - States this part is intended to be used with ISO 8820-1 and ISO 8820-2, reinforcing system-level fuse-path documentation needs.
Open source
S21 · NEMA
Technical Bulletin No. 123 (Approved 2023-03-08): NEMA and IP Ratings for LFMC and Fittings

Accessed on 2026-06-25 · Source date: Technical Bulletin No. 123, approved 2023-03-08

  • - States IP ratings apply in installed systems and that the overall conduit-fitting-enclosure system is limited by the lowest-rated component.
  • - States NEMA enclosure Types include additional hazard coverage and are not fully equivalent one-to-one with IP ratings.
Open source
S22 · ISO
ISO 8820-2:2014 Road Vehicles - Fuse-links - Part 2: User Guidelines

Accessed on 2026-06-25 · Source date: Edition 3 published 2014-02; confirmed current in 2020

  • - Abstract says fuse-links in the ISO 8820 family are intended for electrical cable protection.
  • - Abstract states component protection use requires customer-supplier agreement and emphasizes parameter-based fuse selection.
Open source
S23 · ISO
ISO 16750-5:2023 Road Vehicles - Environmental Conditions and Testing - Chemical Loads

Accessed on 2026-06-25 · Source date: Edition 3 published 2023-06

  • - Abstract defines chemical-load test scope for vehicle E/E systems and components by mounting location context.
  • - Abstract note states continuous-contact chemical conditions may require other standards or explicit customer-supplier agreement.
Open source
S24 · CISPR
CISPR 25 Vehicles, boats and internal combustion engines - Radio disturbance characteristics

Accessed on 2026-06-25 · Source date: Edition 5.0 published 2021-12-16; stability date 2026

  • - IEC product page identifies CISPR 25 as an International Standard, edition 5.0, published 2021-12-16, with stability date 2026.
  • - Critical for brushed DC motors used in micro linear actuators, as commutator arcing generates broadband high-frequency noise requiring filtering.
Open source
S25 · ISO
ISO 16750-3:2023 Road Vehicles - Environmental Conditions and Testing - Mechanical Loads

Accessed on 2026-09-29 · Source date: Edition 4 published 2023-07

  • - Specifies the environmental conditions and testing requirements for mechanical loads, including vibration and shock, based on mounting location.
  • - Essential boundary check for micro actuators with delicate gearing and brush-commutator contacts that can fail under vehicle-specific structural stress.
Open source
S26 · European Commission / EUR-Lex
Machinery legislation: application dates and product classification

Accessed on 2026-10-22 · Source date: Commission guidance checked 2026-10-22; links to consolidated Regulation (EU) 2023/1230

  • - General application starts on 20 January 2027; the Commission links the corrected and consolidated regulation.
  • - Classify the supplied product before deciding whether machinery or partly completed machinery documentation is required. Article 11 and Annex V Part B address incorporation documentation where that classification applies.
Open source
S27 · European Commission
Low Voltage Directive: voltage scope

Accessed on 2026-10-22 · Source date: Directive applicable since 2016-04-20; voltage scope checked 2026-10-22

  • - LVD covers equipment with input or output voltage between 50 and 1000 V AC or 75 and 1500 V DC.
  • - This voltage scope alone does not determine the obligations for a complete assembly with a mains power supply.
Open source
S28 · European Parliament and Council
Regulation (EU) 2023/988: consumer-product scope

Accessed on 2026-10-22 · Source date: Applies from 2024-12-13; Articles 2, 3 and 16 scope checked 2026-10-22

  • - Scope includes products intended for consumers or reasonably likely to be used by consumers; it does not blanket-cover every industrial component.
  • - Interaction with sector-specific legislation and EU responsible-person obligations must be assessed for the actual product. GPSR is not a standalone CE certification scheme.
Open source
S29 · IEC
IEC 60085:2007 Electrical insulation — Thermal evaluation and designation

Accessed on 2026-10-22 · Source date: Edition 4.0 published 2007-11-07

  • - Public scope covers thermal-endurance evaluation and class assignment for insulation materials and systems.
  • - No universal actuator duty reduction above 40°C is established by that public scope. The exact model’s duty-temperature curve remains required.
Open source
S30 · ASTM International
ASTM B258-18: nominal AWG wire dimensions and properties

Accessed on 2026-10-22 · Source date: Historical 2018 edition; ASTM listing points to 2026 reapproval

  • - Scope concerns nominal diameters, cross-sectional areas and property calculations for solid round AWG wires.
  • - The listing does not establish a universal 18–20 AWG rule or 3% voltage-drop limit for actuator harnesses.
Open source
S31 · Belden
83504 cable technical data: resistance and current rating example

Accessed on 2026-10-22 · Source date: Datasheet revision 0.511; reviewed 2026-10-22

  • - Lists 24 AWG tinned copper, nominal conductor DCR 24 ohm/1000 ft and maximum 1.6 A per conductor at 25°C.
  • - Calculated illustration only: 3.5 A × 4 m × (24 ohm / 304.8 m) = 1.10 V, about 9.2% of 12V. This exceeds the listed current rating and is not a cable recommendation.
Open source
S32 · Schneider Electric
SELV: protective separation and fault-condition requirements

Accessed on 2026-10-22 · Source date: Manufacturer explanation updated 2024-08-20

  • - Explains protective separation and voltage limits under normal and single-fault conditions for SELV systems.
  • - A nominal 12V label alone does not prove those system properties.
Open source
S33 · LINAK A/S
LA14 actuator user manual: side-loading restriction

Accessed on 2026-10-22 · Source date: LA14 user manual; reviewed 2026-10-22

  • - LA14 operating instructions prohibit side loading and require use within the specified working limits.
  • - This model-specific restriction does not establish numerical side-load limits or failure loads for other mini/micro actuators.
Open source
S34 · Progressive Automations
PA-14 user manual V1.03: specifications, dimensions and load curves

Accessed on 2026-10-22 · Source date: V1.03; linked from manufacturer resources, reviewed 2026-10-22

  • - Lists separate load-speed options and 5 A full-load current at 12V. Full-load current is not a startup or stall-current rating.
  • - Lists 25% duty with 5 minutes on / 15 minutes off, IP54 (IP65 customizable), dimensioned drawings and load curves. Apply the selected option’s data.
Open source
S35 · Thomson Linear
What is side loading and how does it affect my actuator?

Accessed on 2026-10-22 · Source date: Manufacturer support article; reviewed 2026-10-22

  • - Explains how radial loads can cause misalignment, binding and damage in industrial actuators; loads should follow the extension axis.
  • - Distinguishes precision actuators with extra side-load bearing support. It does not provide universal numerical side-load or failure thresholds.
Open source
Prepare your actuator review
Bring your requirements and a candidate datasheet to engineering. The review link carries your current inputs into the inquiry form.

Requirements and related tools